fig7
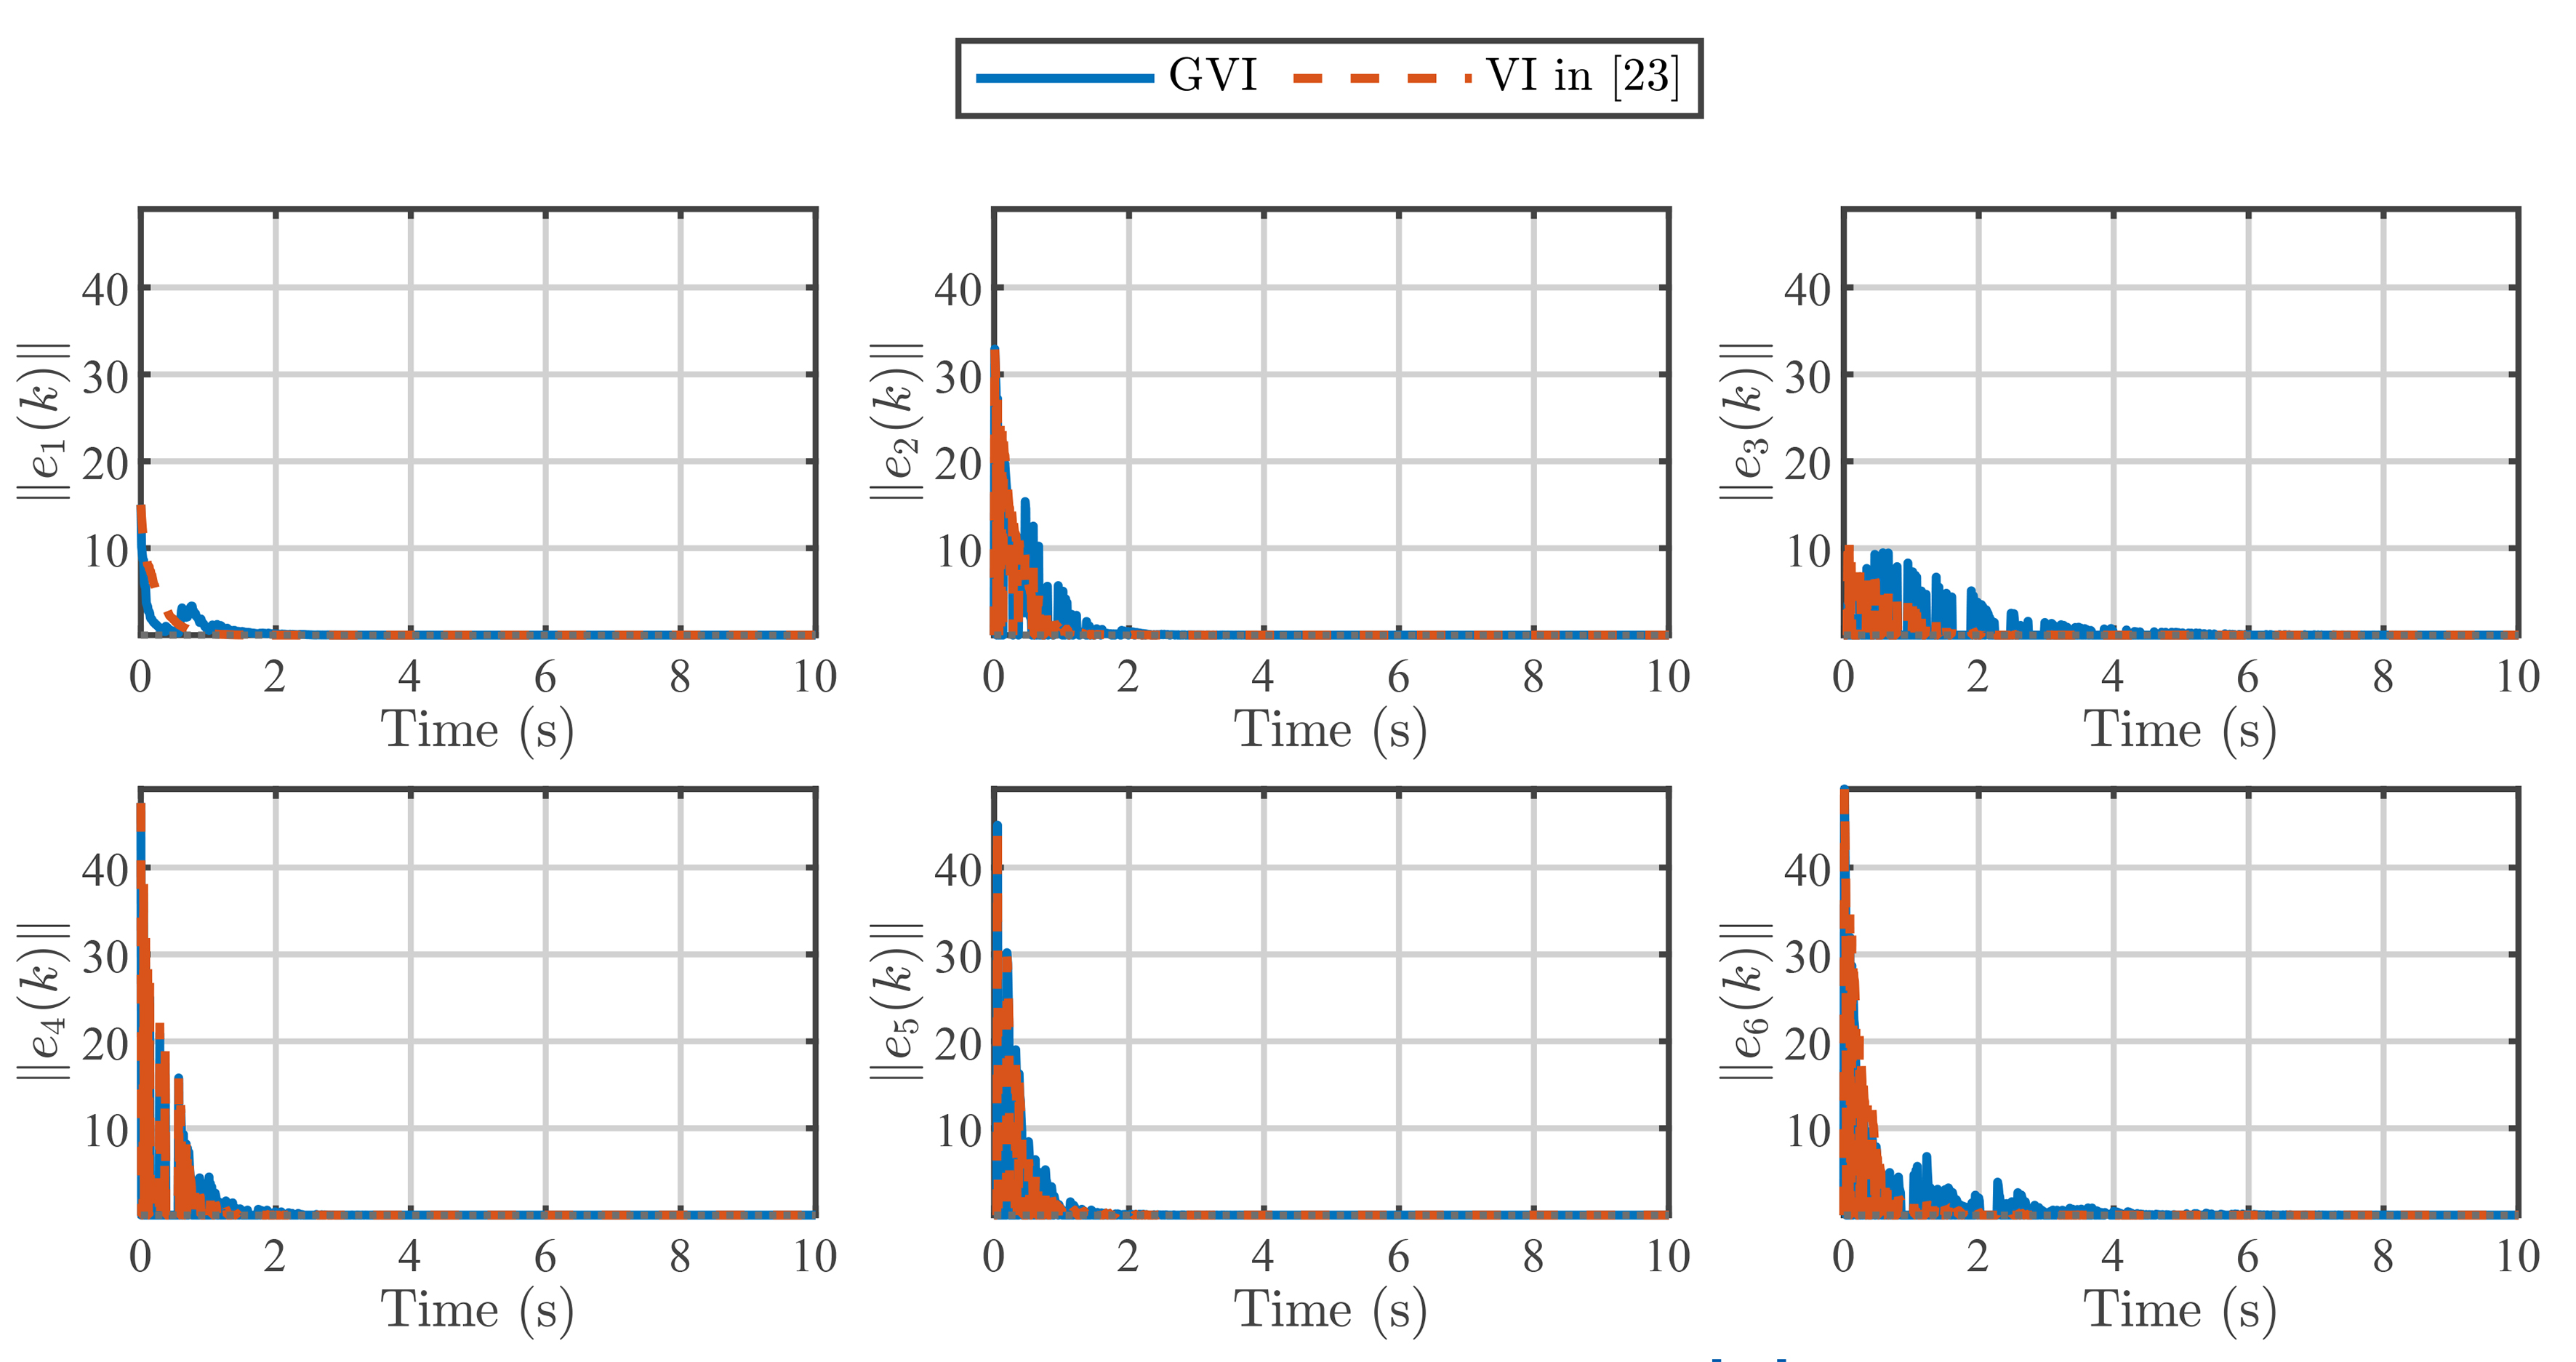
Figure 7. The norm of the tracking error for each agent under VI in[23] and GVI. VI: Value iteration; GVI: global value iteration.
Figure 7. The norm of the tracking error for each agent under VI in[23] and GVI. VI: Value iteration; GVI: global value iteration.
All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/