fig3
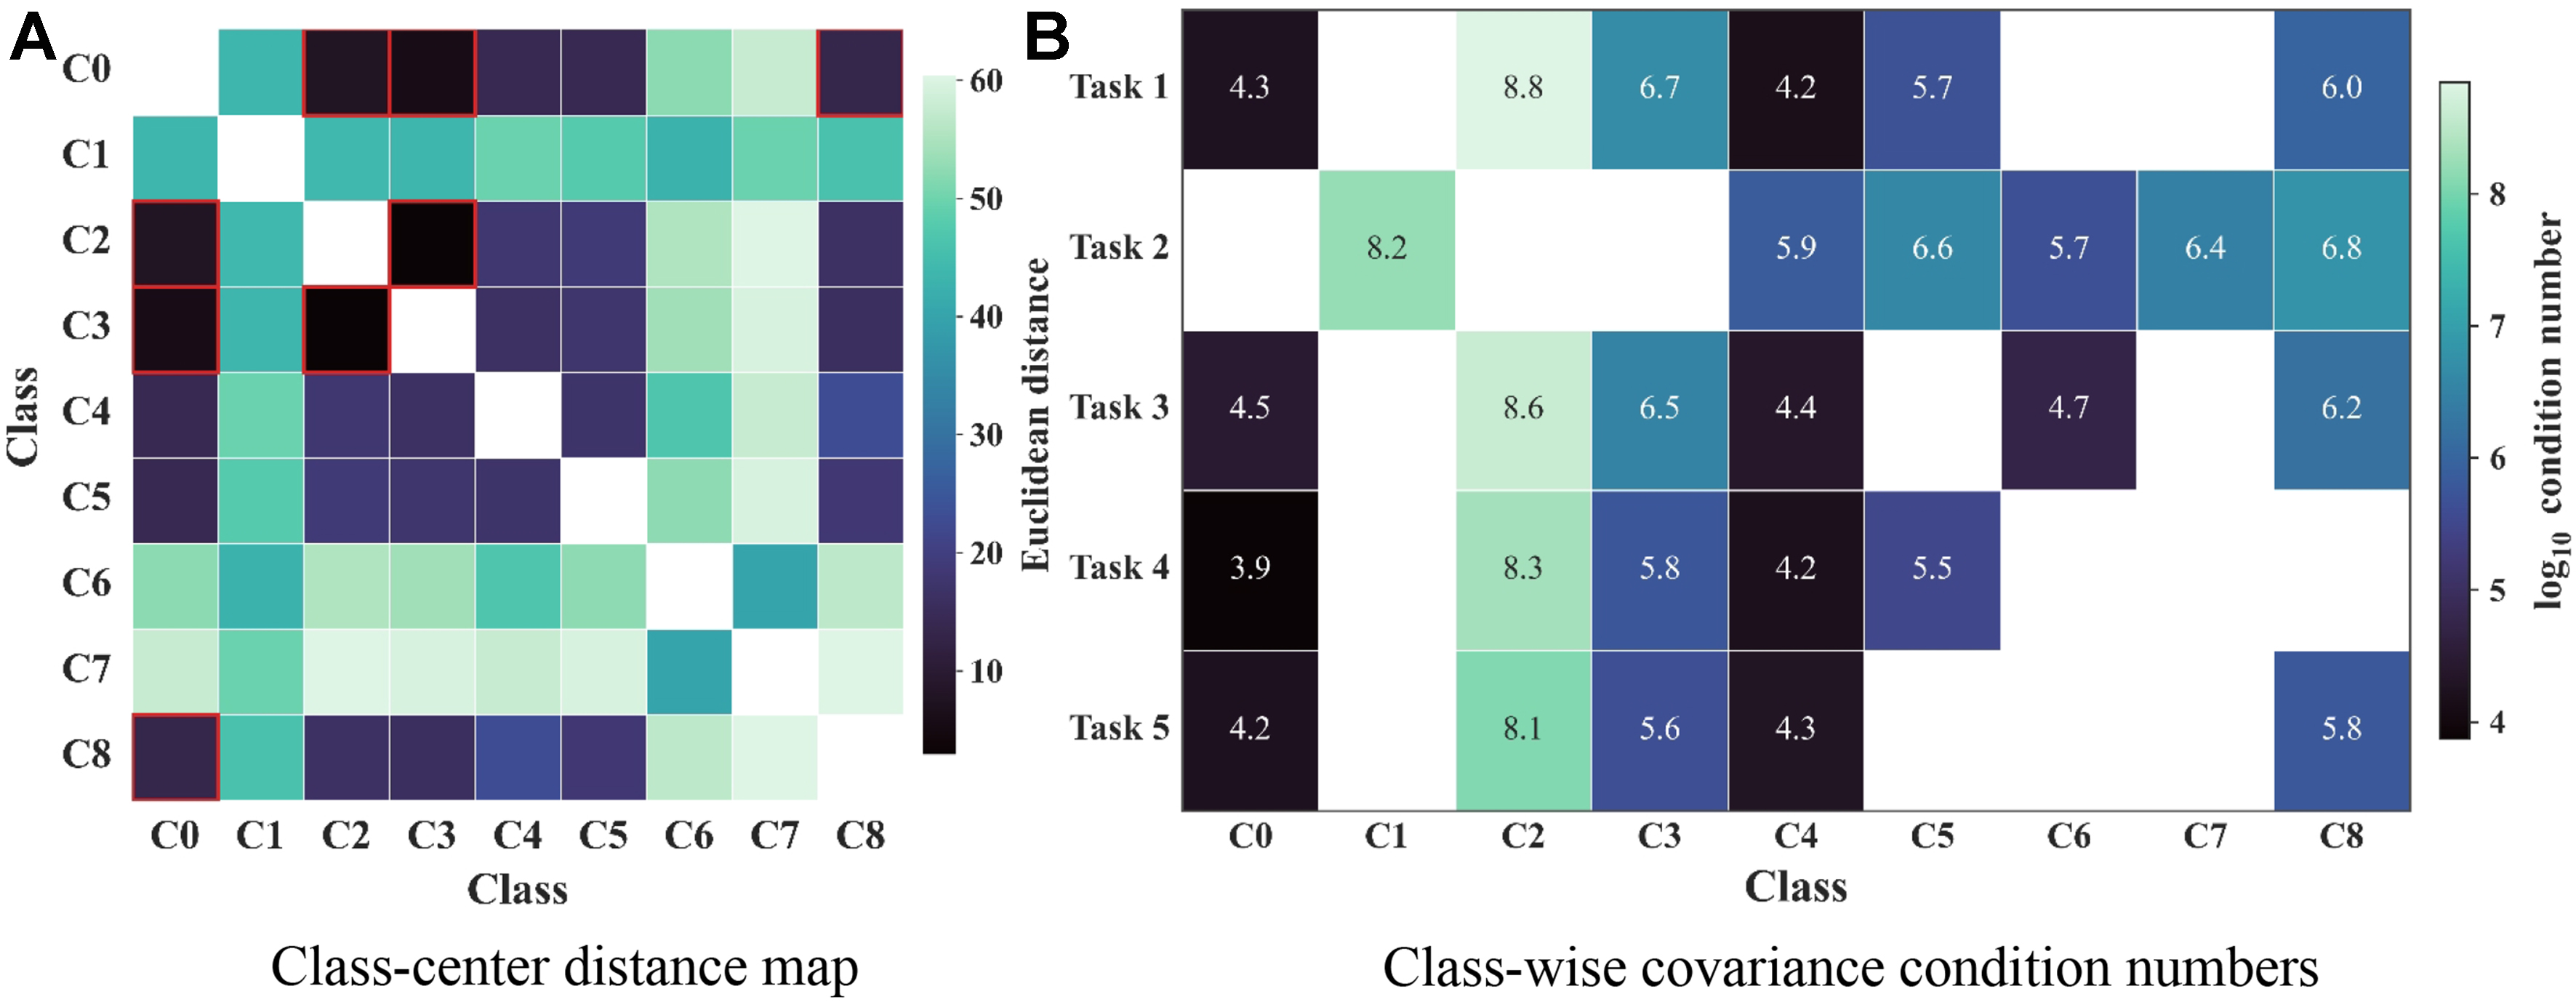
Figure 3. Class-center distance and covariance condition analysis. (A) Normalized class-center Euclidean distance map used to guide open-set task construction. Darker cells indicate smaller inter-class distances, and red boxes highlight closely spaced class pairs; (B) Class-wise full-covariance condition numbers estimated from latent features in the proper training split. Larger values indicate greater potential numerical instability when applying full-covariance Mahalanobis distance.