fig8
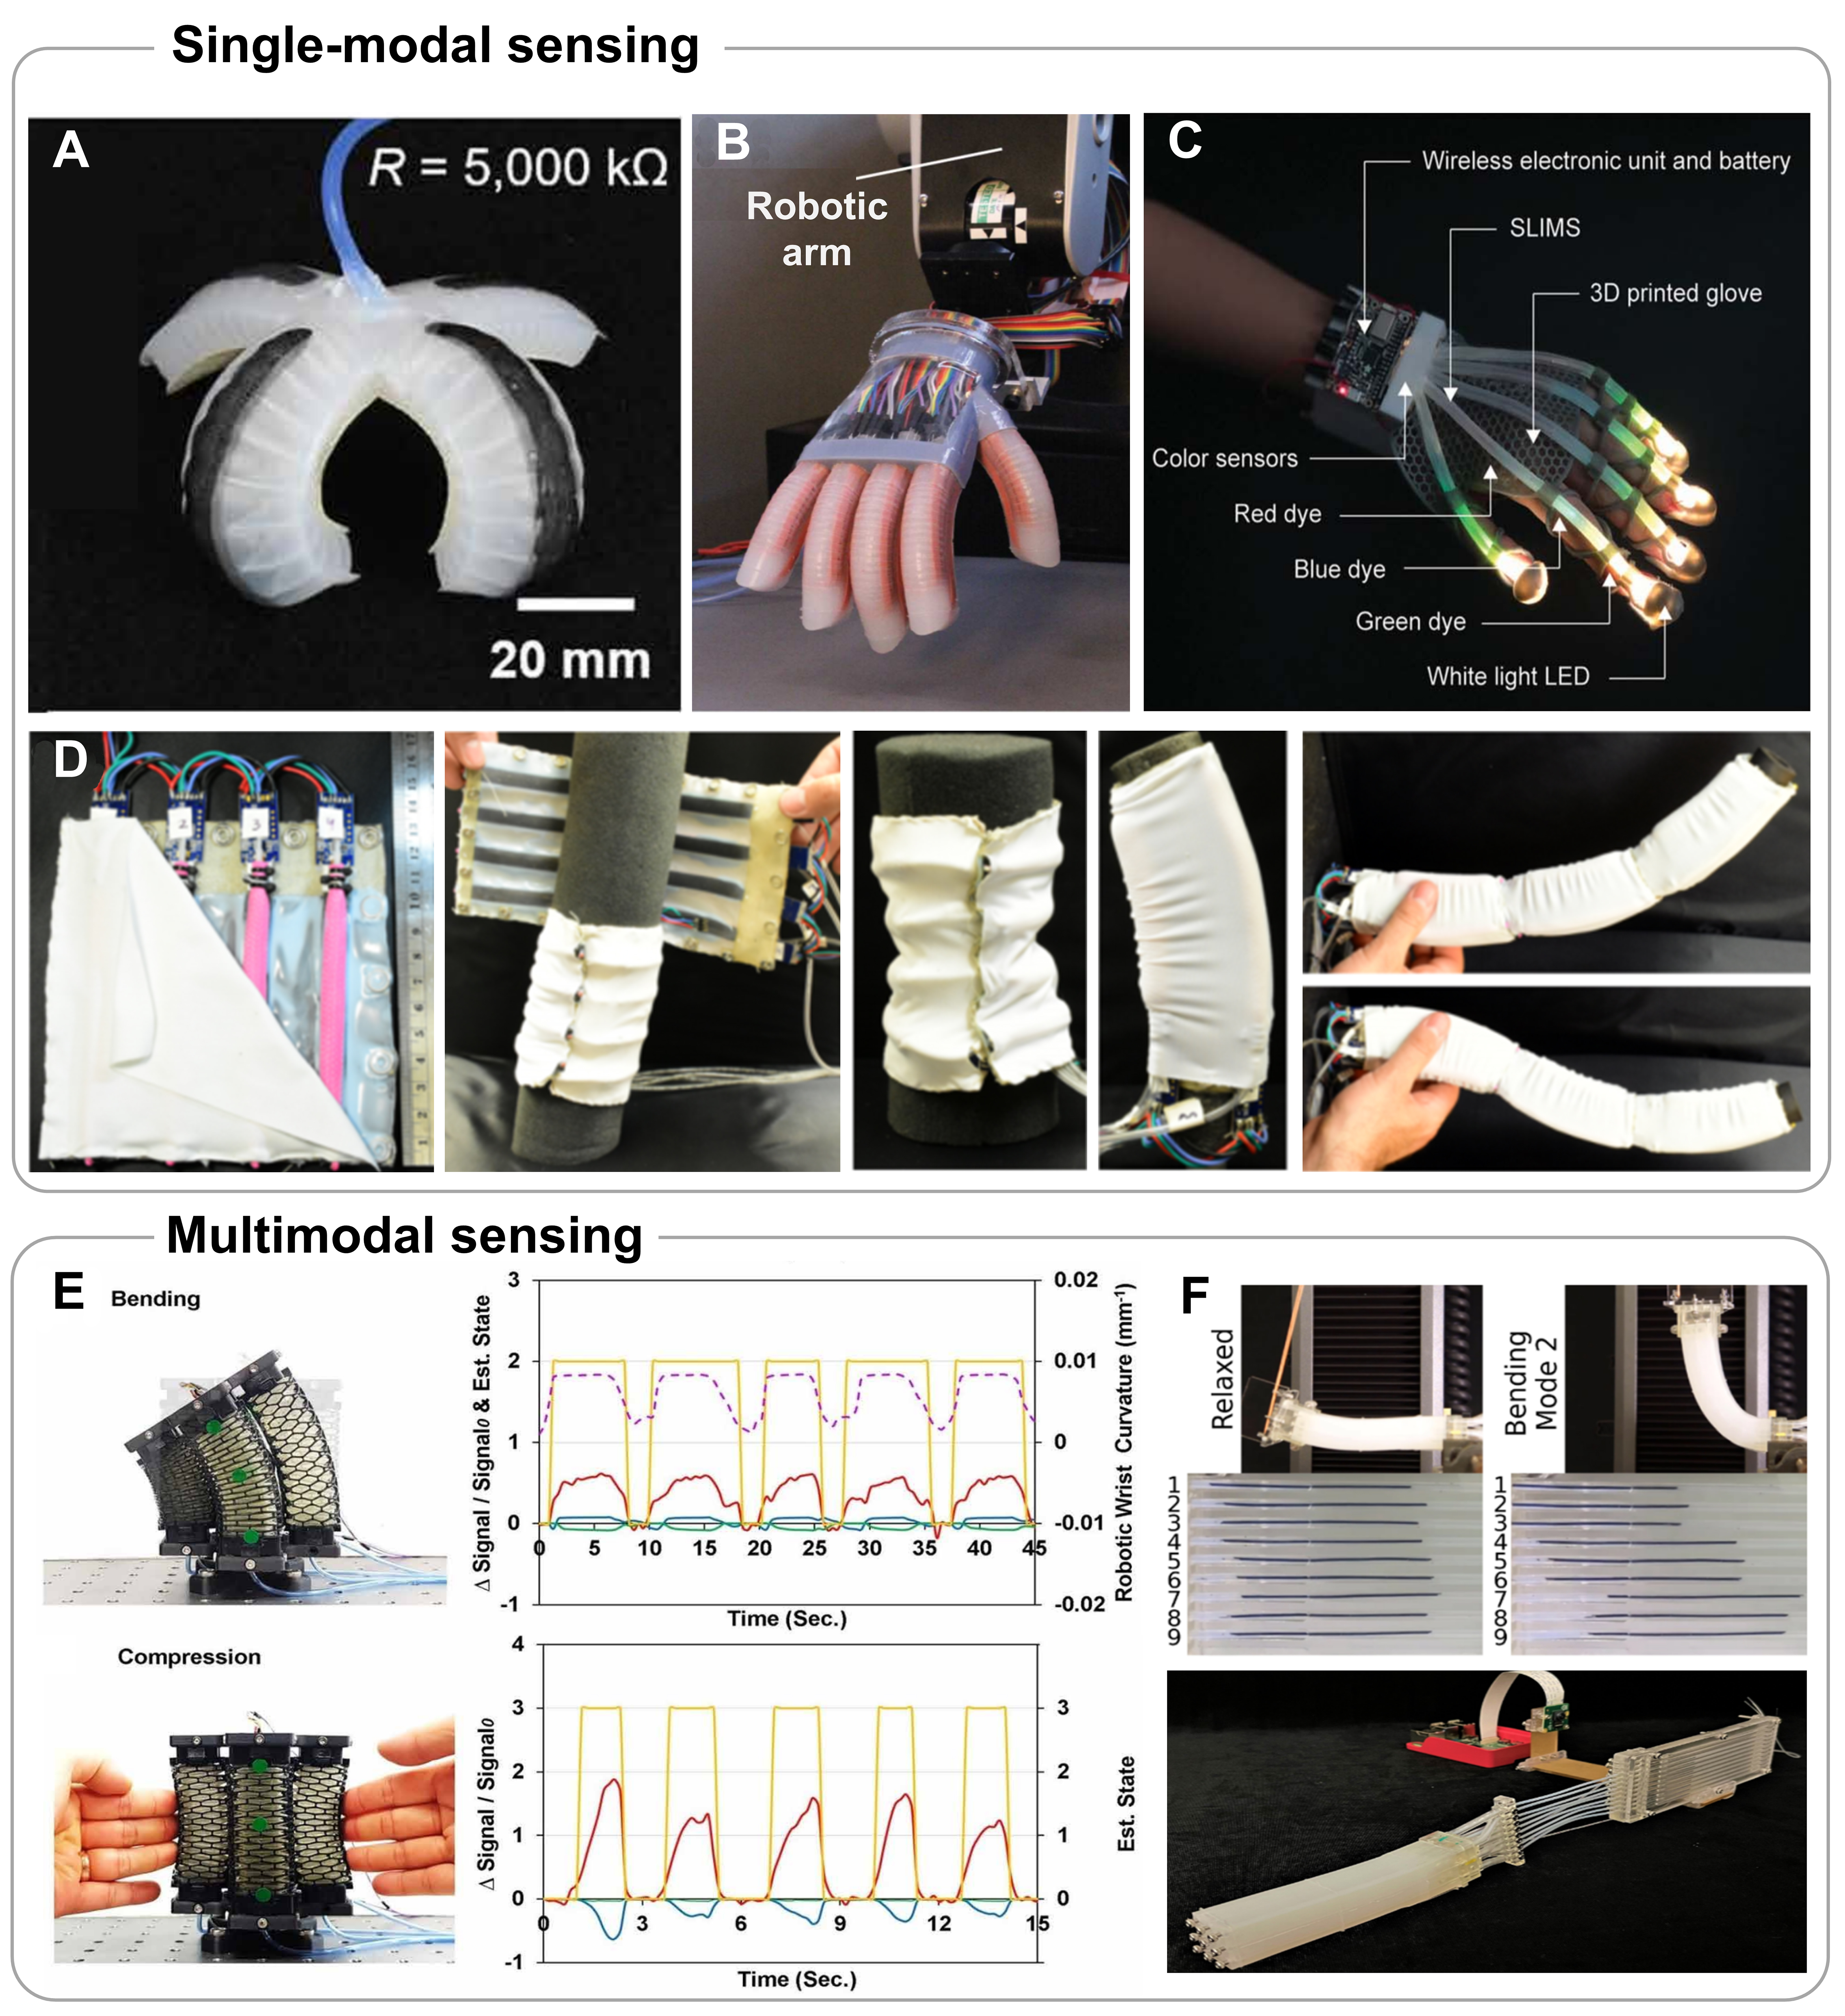
Figure 8. Application of flexible sensors in the proprioception of soft robot. (A) A silicone rubber four-legged gripper, onto which SCP emulsion traces are printed. Adapted with permission from Ref.[218], Copyright © 2020, AAAS; (B) Image of the fabricated hand mounted on a robotic arm with each finger. Adapted with permission from Ref.[229], Copyright © 2016, AAAS; (C) Image of the SLIMS-integrated soft glove with LED light source and electronics module. Adapted with permission from Ref.[230], Copyright © 2020, AAAS; (D) Robotic skins embed distributed actuation and sensing into a conformable substrate to produce different forms of motion effects. Adapted with permission from Ref.[234], Copyright © 2018, AAAS; (E) Different deformation modes by self-actuation as well as human inputs and corresponding sensor data. Adapted with permission from Ref.[235], Copyright © 2020, AAAS; (F) Fiber-based deformation sensors, relaxed and bent states. Adapted from Ref.[236], under CC BY 4.0 license. SCP: Self-coagulating conductive Pickering; SLIMS: stretchable lightguide for multimodal sensing; LED: light emitting diode.