fig11
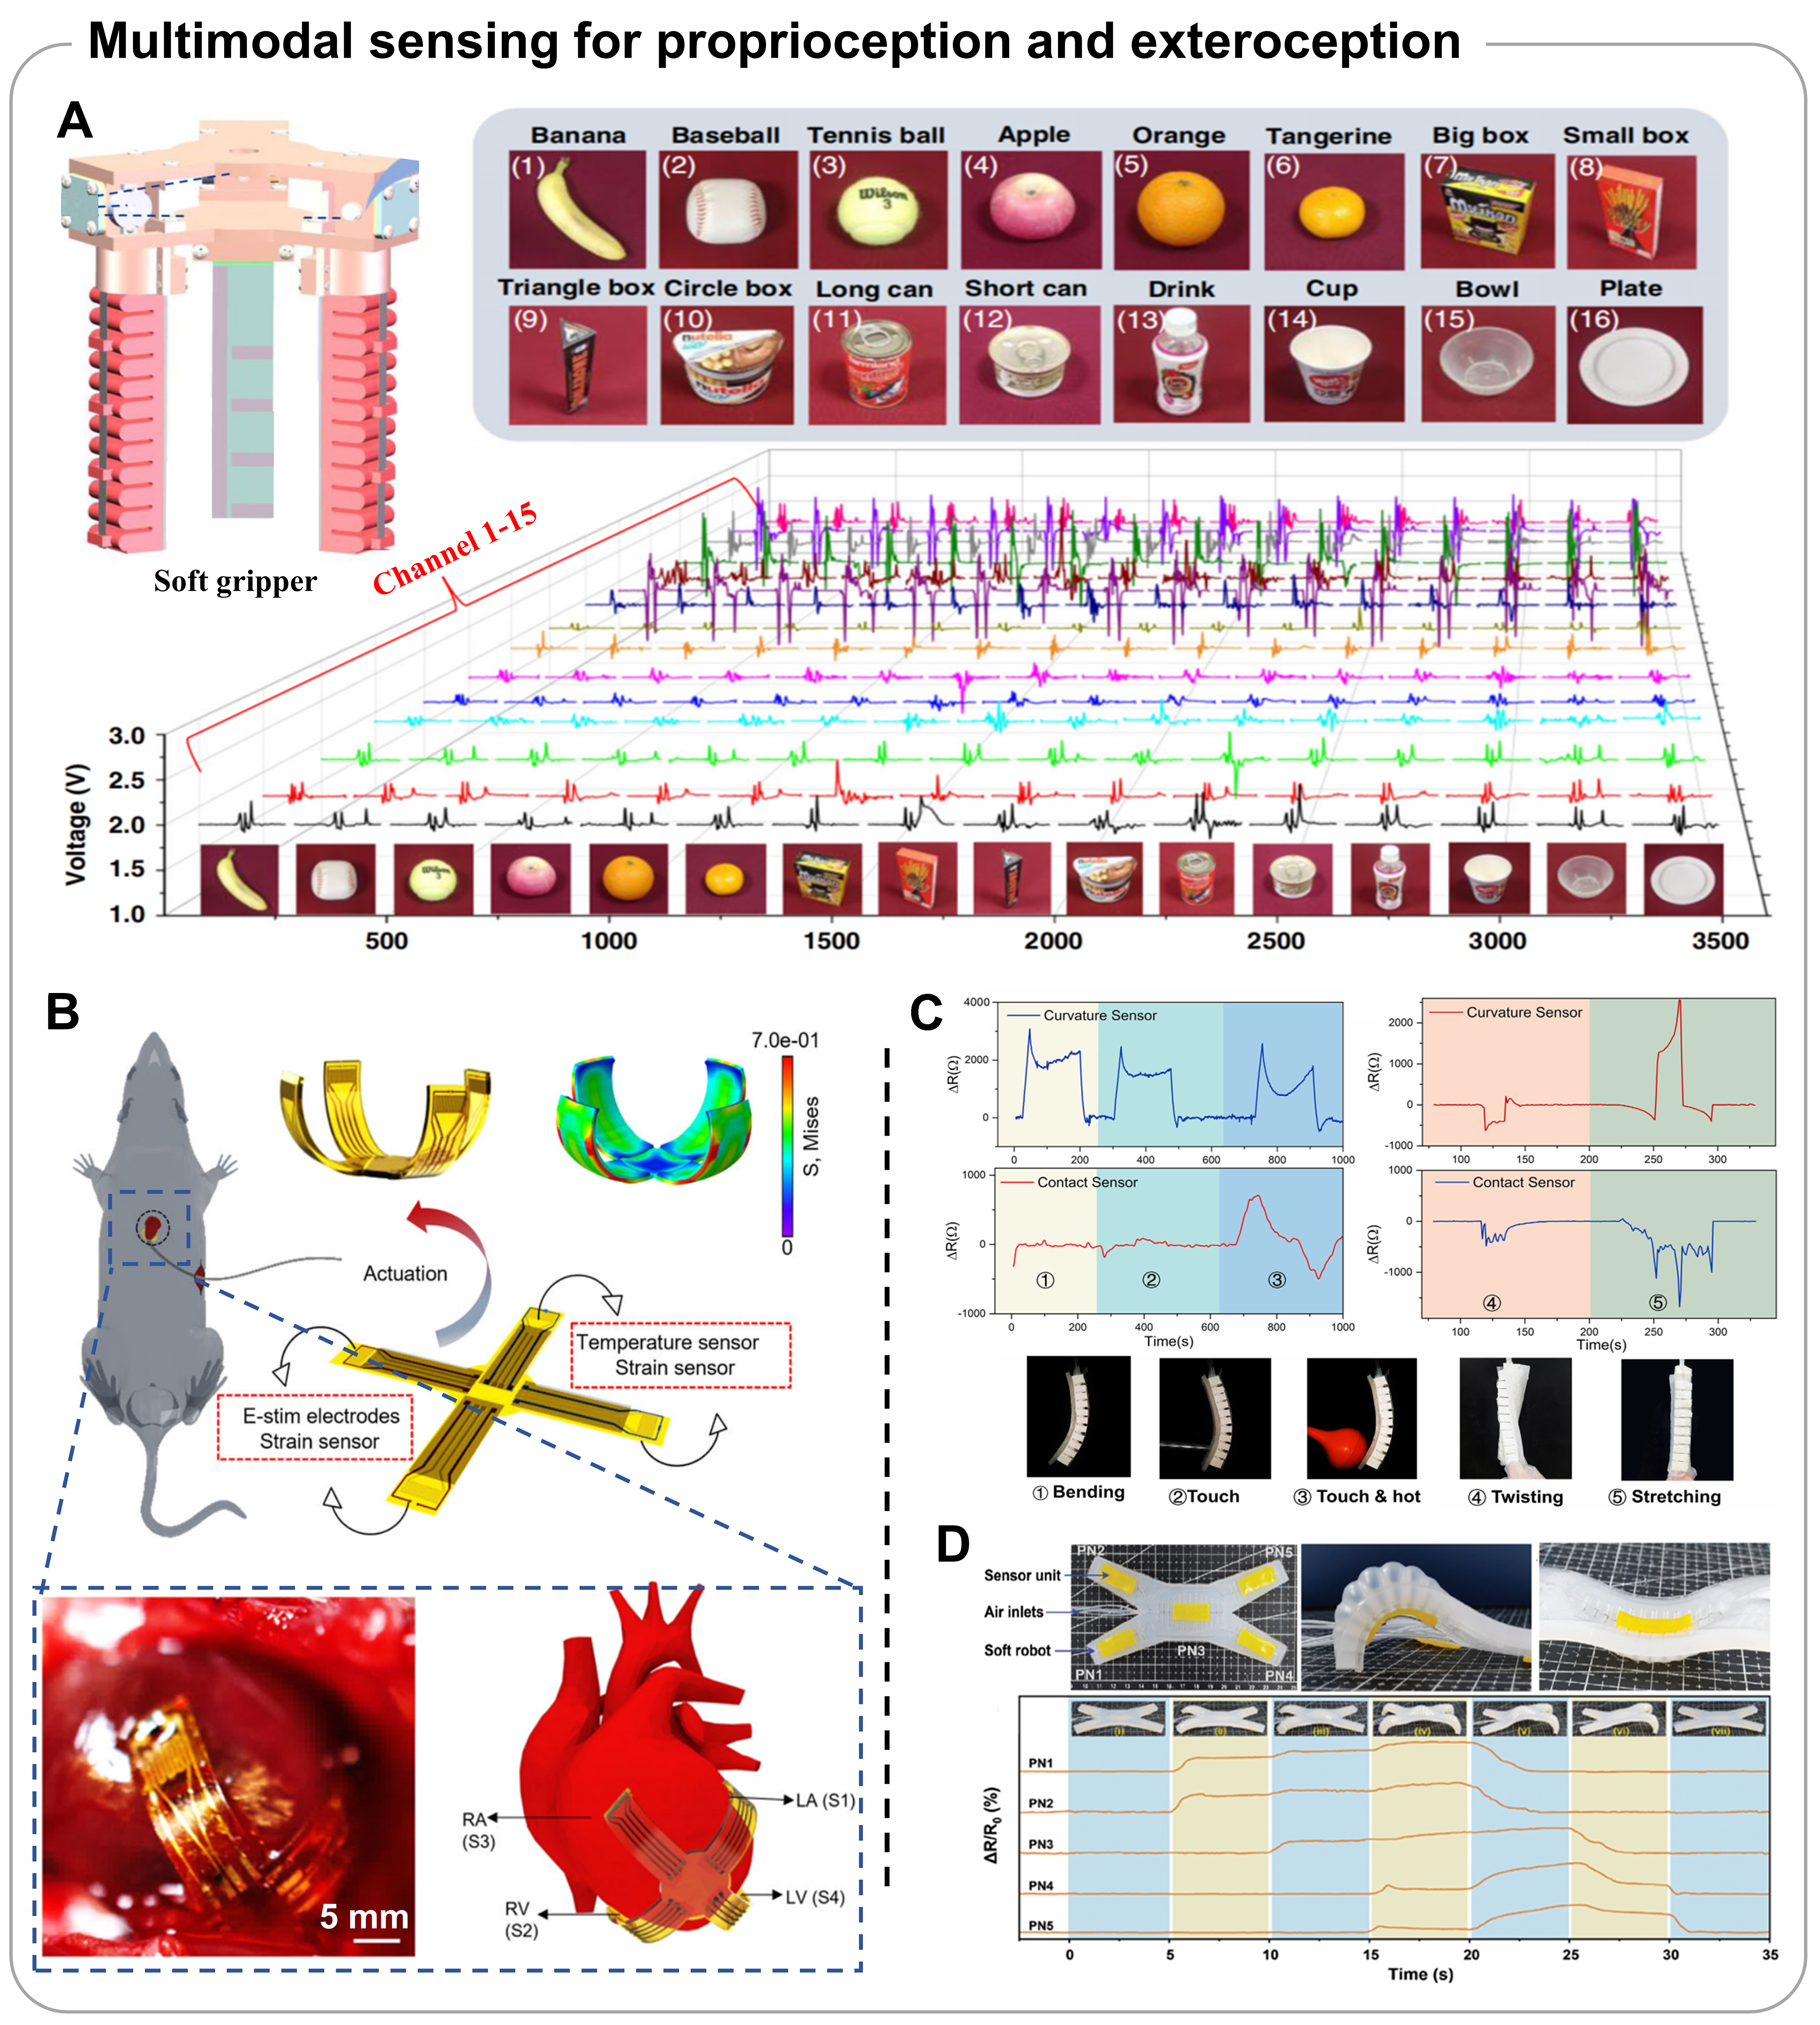
Figure 11. Representative multimodal sensing systems for integrated proprioception and exteroception in soft robots. (A) Enhanced object recognition system via machine learning technology. Adapted from Ref.[265], under CC BY 4.0 license; (B) In vivo validation of a soft robotic thera-gripper for epicardial sensing and electrical stimulation (E-stim). Adapted from Ref.[266], under CC BY 4.0 license; (C) Two flexible sensors detect the contact events and mechanical deformation of the soft actuator. Adapted from Ref.[267], under CC BY 4.0 license; (D) Demonstration of the sensors integrated with the soft robot for motion and material recognition. Adapted with permission from Ref.[268], Copyright © 2023 Wiley-VCH GmbH.