fig4
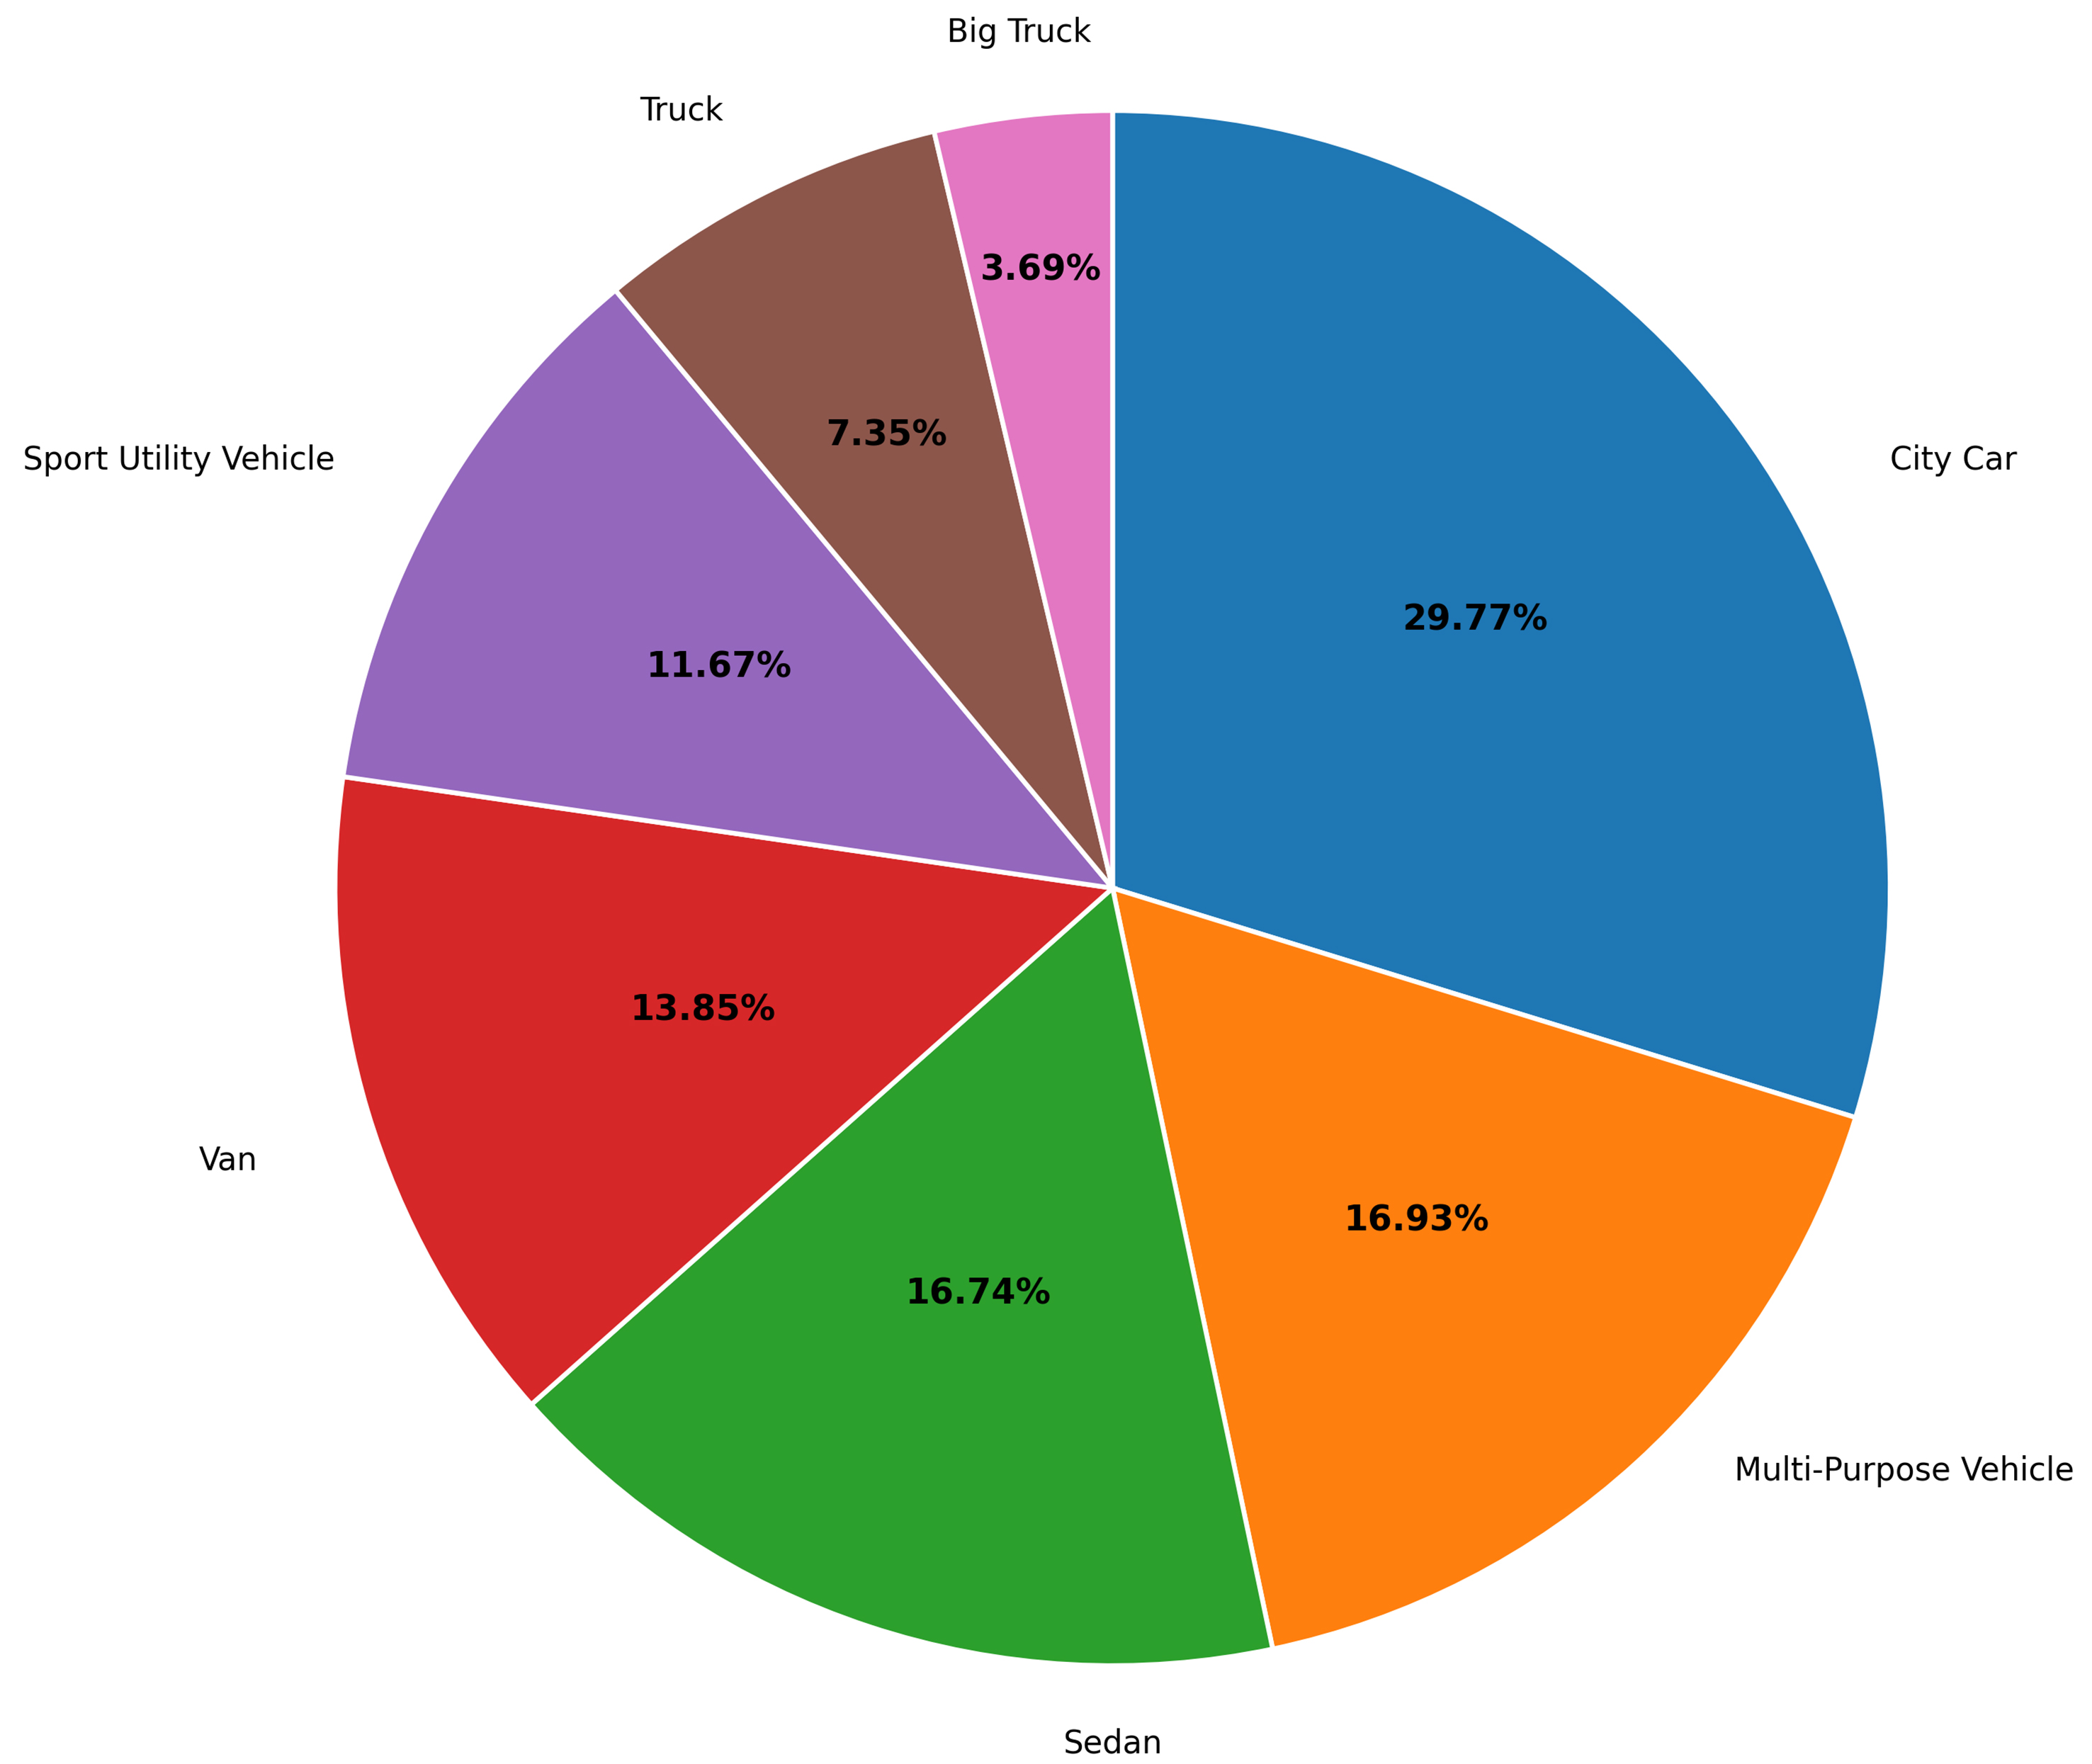
Figure 4. Percentage distribution of samples across different classes using a pie chart.
Figure 4. Percentage distribution of samples across different classes using a pie chart.
All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/