fig22

A two-stage context-aware meta-ensemble framework for collision risk prediction in Internet of Vehicles

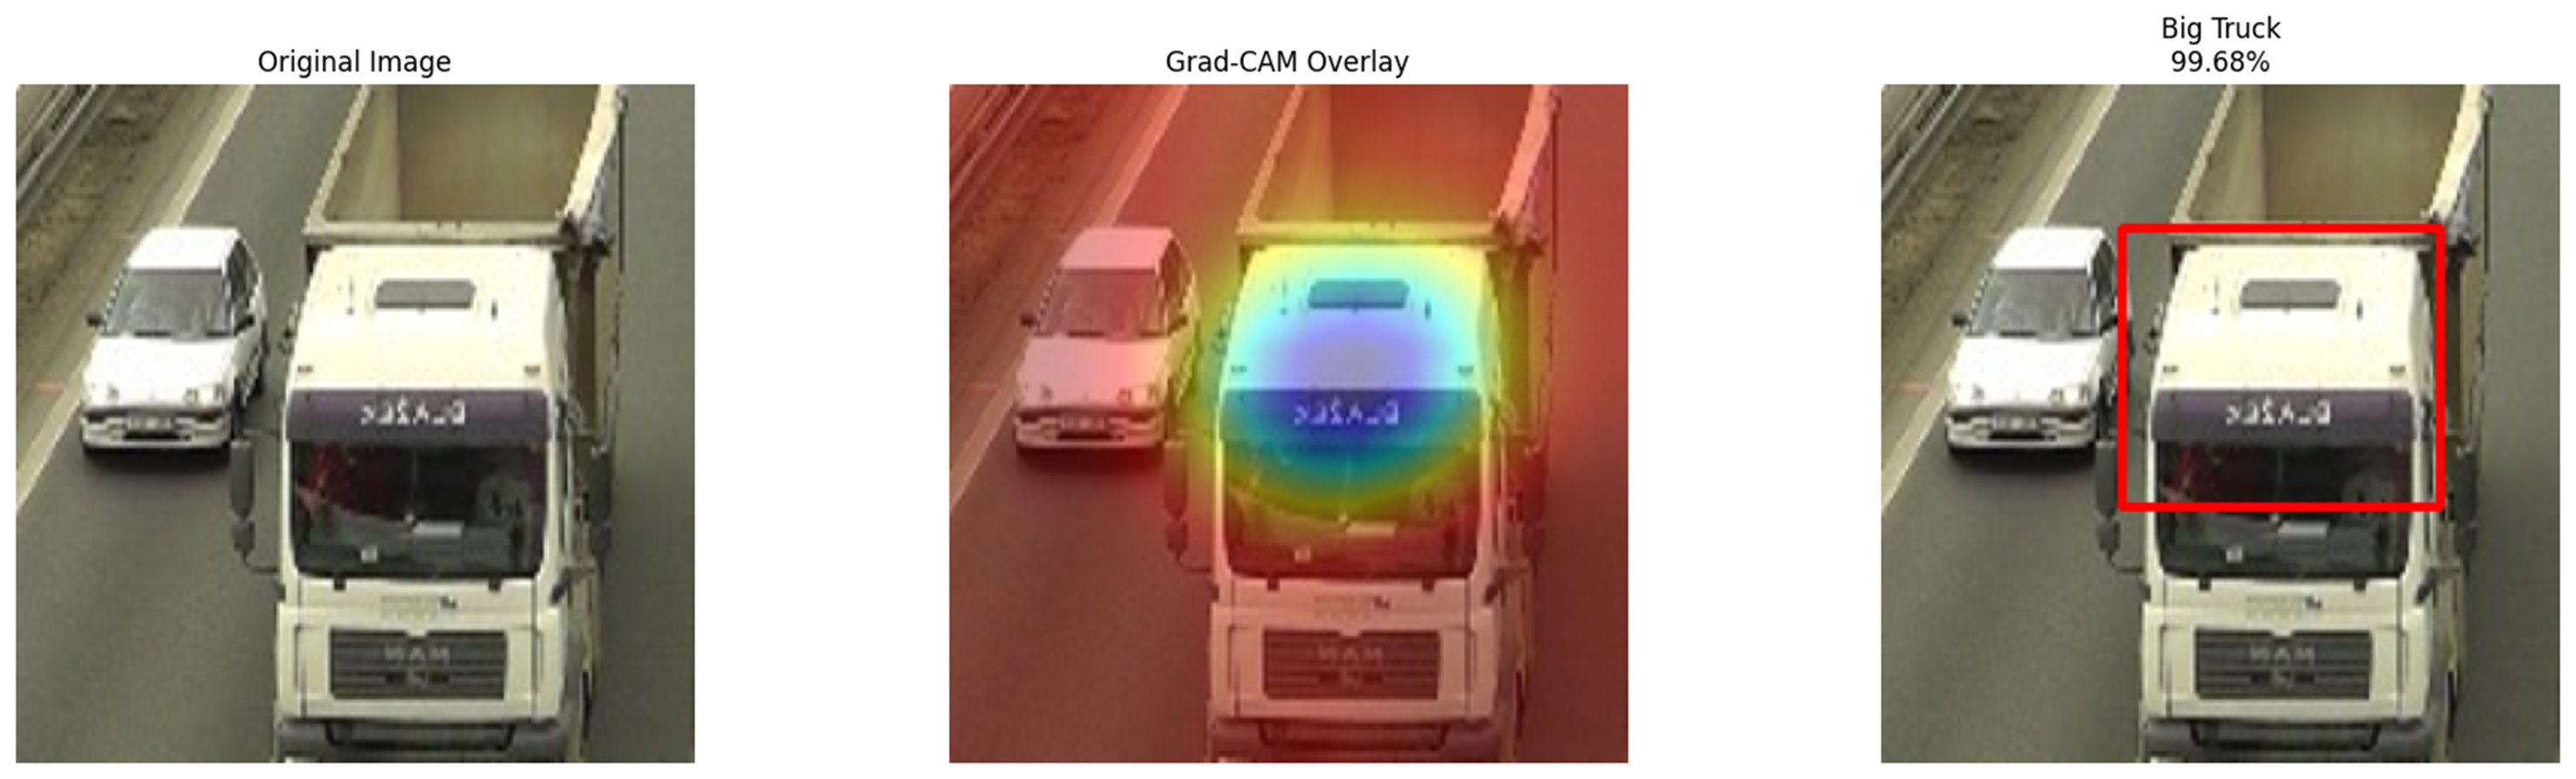
Figure 22. Grad-CAM visualization for big truck classification demonstrating high-confidence feature localization (The original vehicle samples are selected from the Vehicle Images Dataset[26]). Grad-CAM: Gradient-weighted class activation mapping.

Intelligence & Robotics
ISSN 2770-3541 (Online)

Portico

All published articles are preserved here permanently:

https://www.portico.org/publishers/oae/

Portico

All published articles are preserved here permanently:

https://www.portico.org/publishers/oae/