fig2
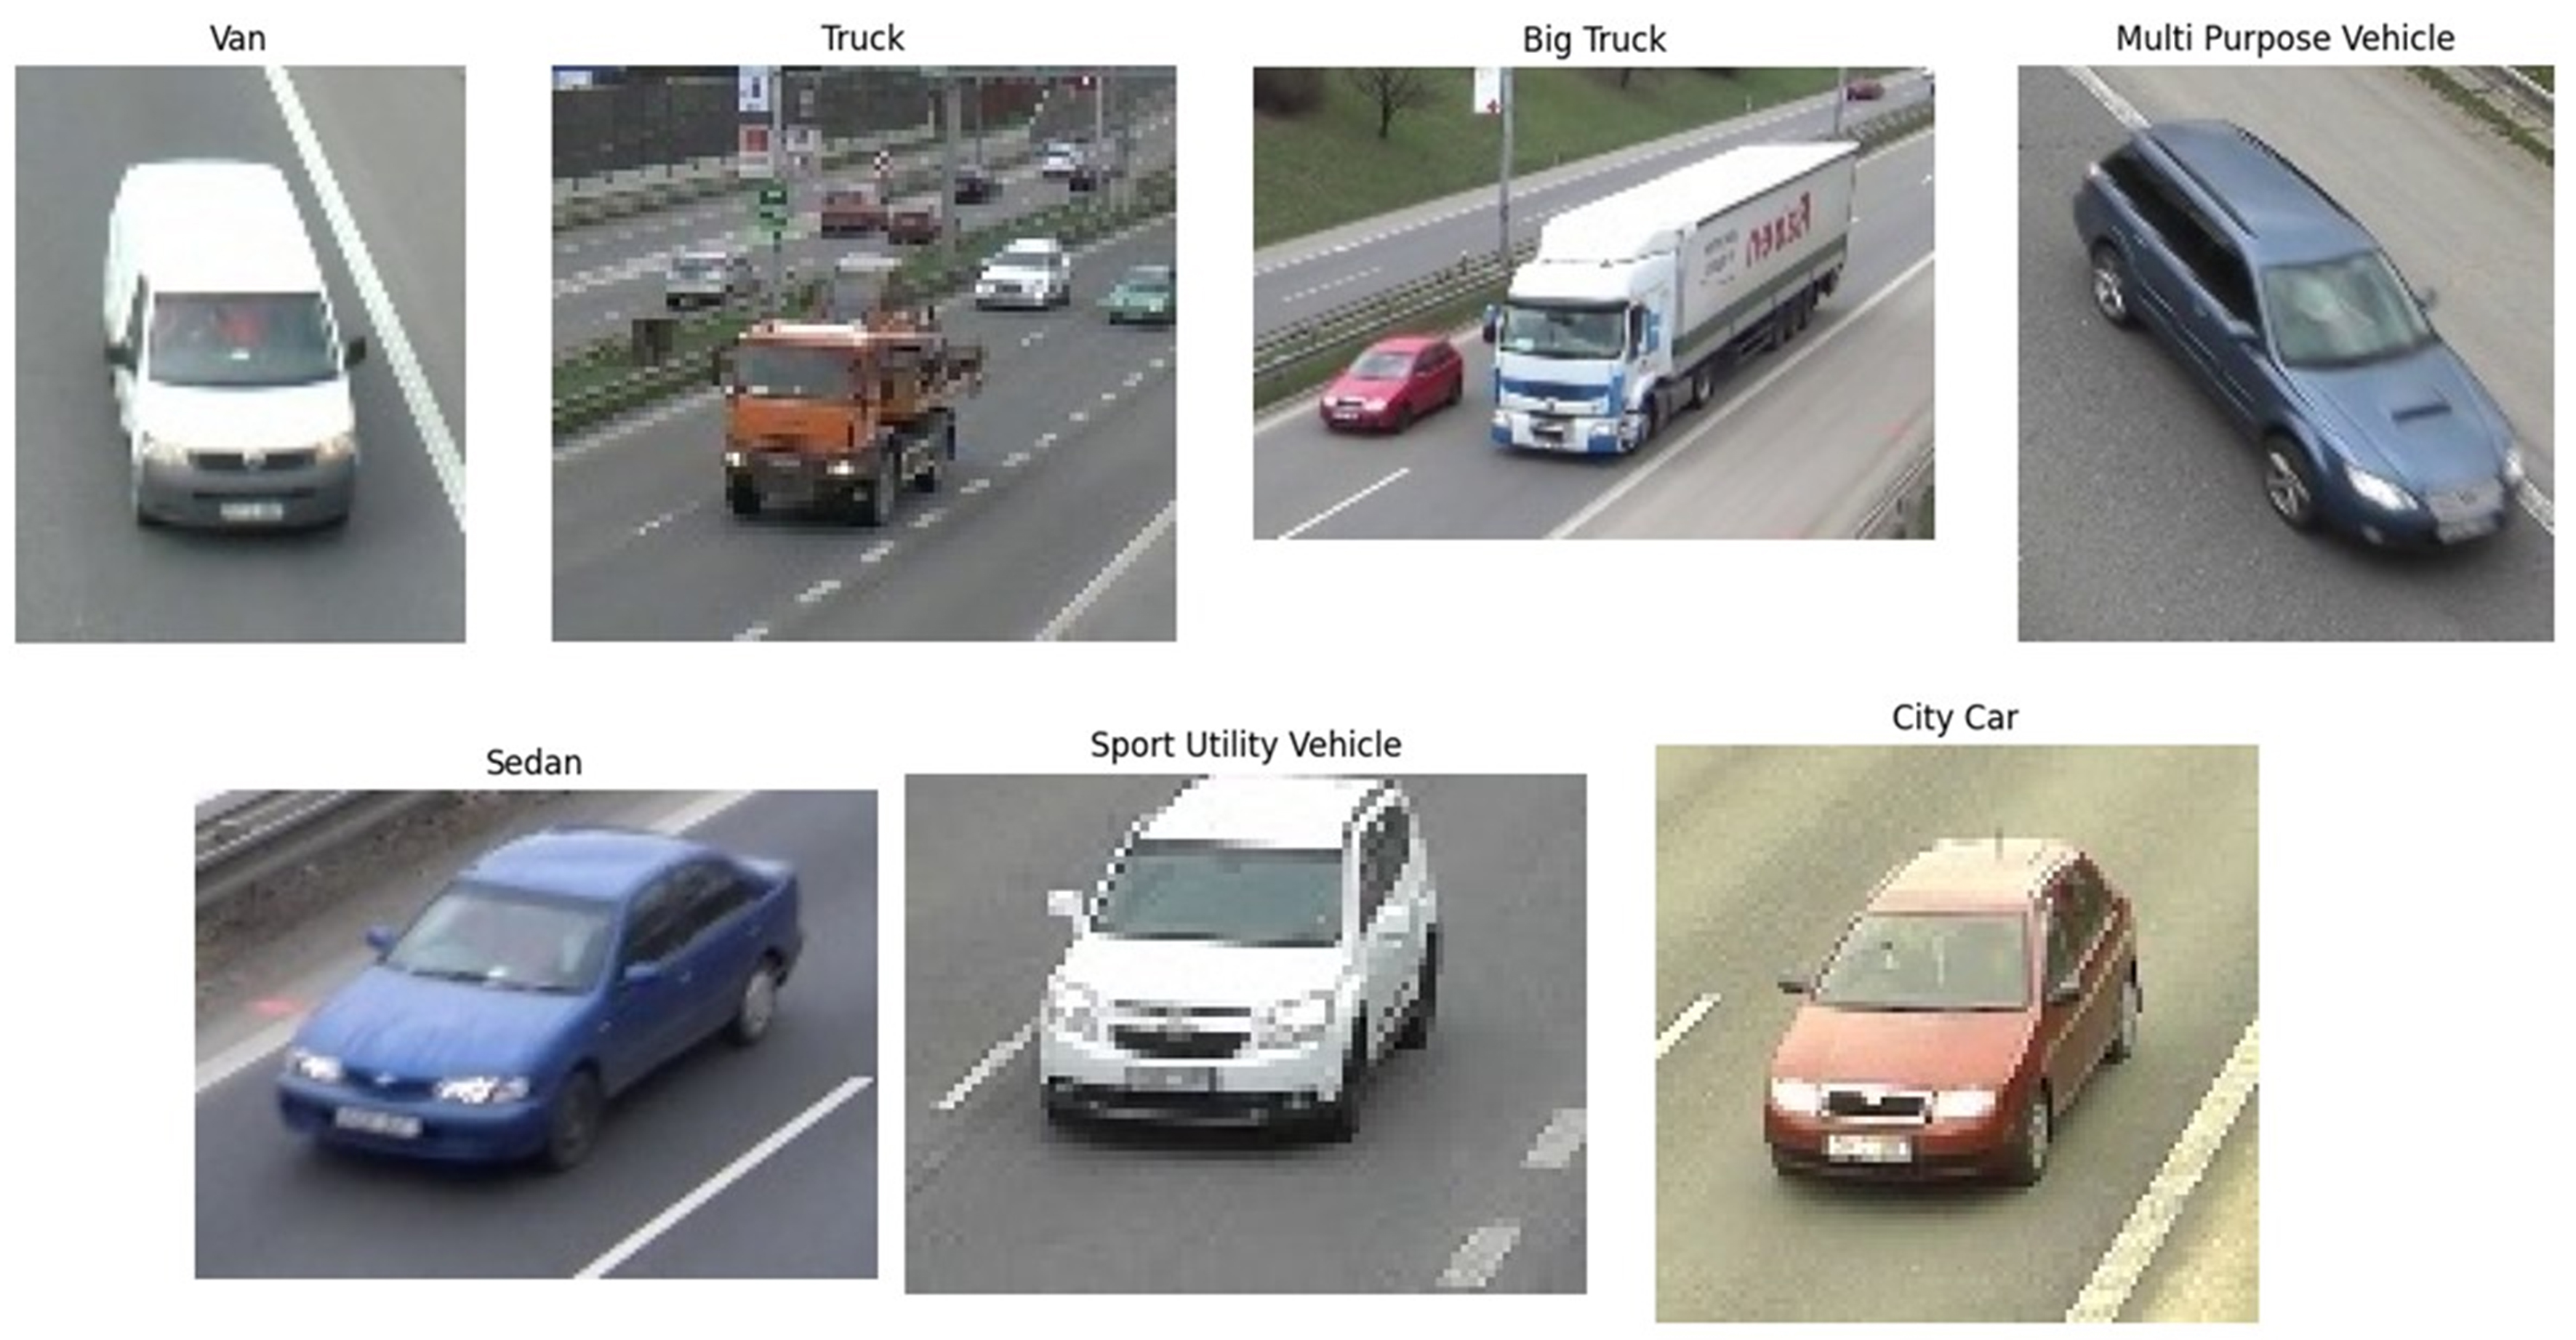
Figure 2. Representative sample from each category (the original vehicle samples are selected from the Vehicle Images Dataset[26]).
Figure 2. Representative sample from each category (the original vehicle samples are selected from the Vehicle Images Dataset[26]).
All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/