
fig9
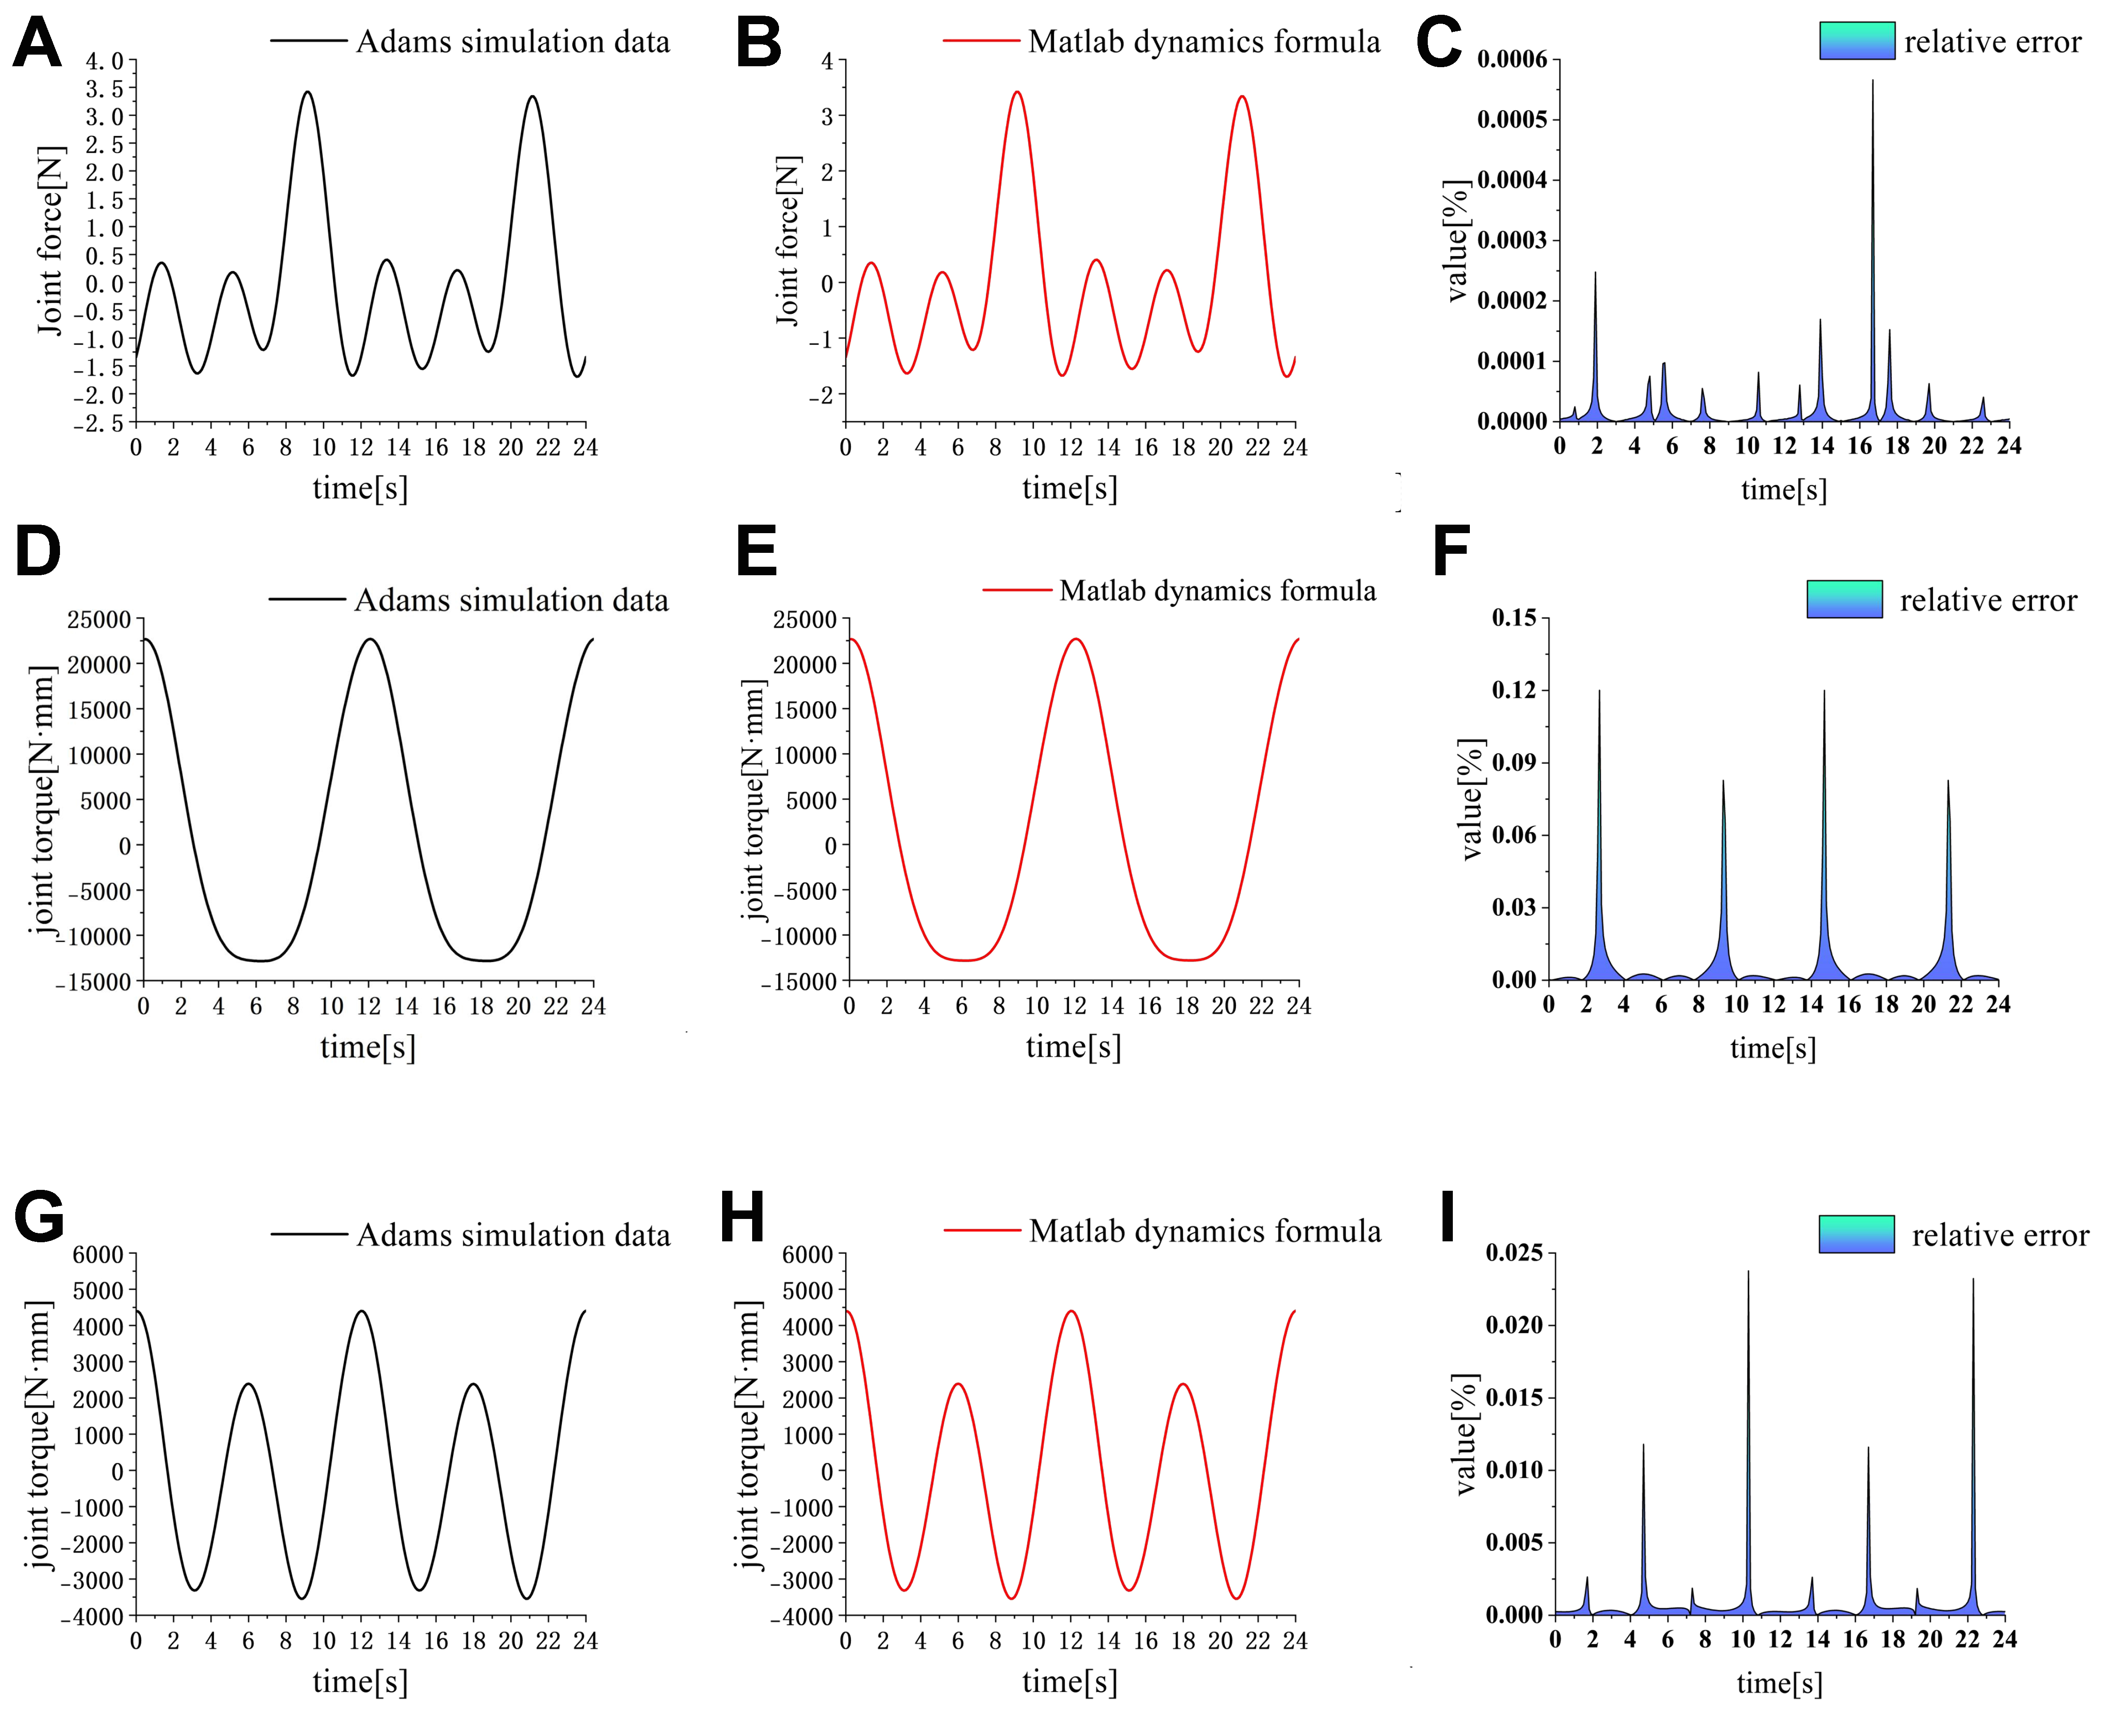
Figure 9. Comparison of joint forces and torques of the picking mechanism between MATLAB-based dynamic formulations and ADAMS simulation data. (A) ADAMS simulation of translational arm joint force; (B) MATLAB-based dynamic result of translational arm joint force; (C) Relative error of translational arm joint force; (D) ADAMS simulation of picking main arm joint torque; (E) MATLAB-based dynamic result of picking main arm joint torque; (F) Relative error of picking main arm joint torque; (G) ADAMS simulation of picking secondary arm joint torque; (H) MATLAB-based dynamic result of picking secondary arm joint torque; (I) Relative error of picking secondary arm joint torque.