fig6
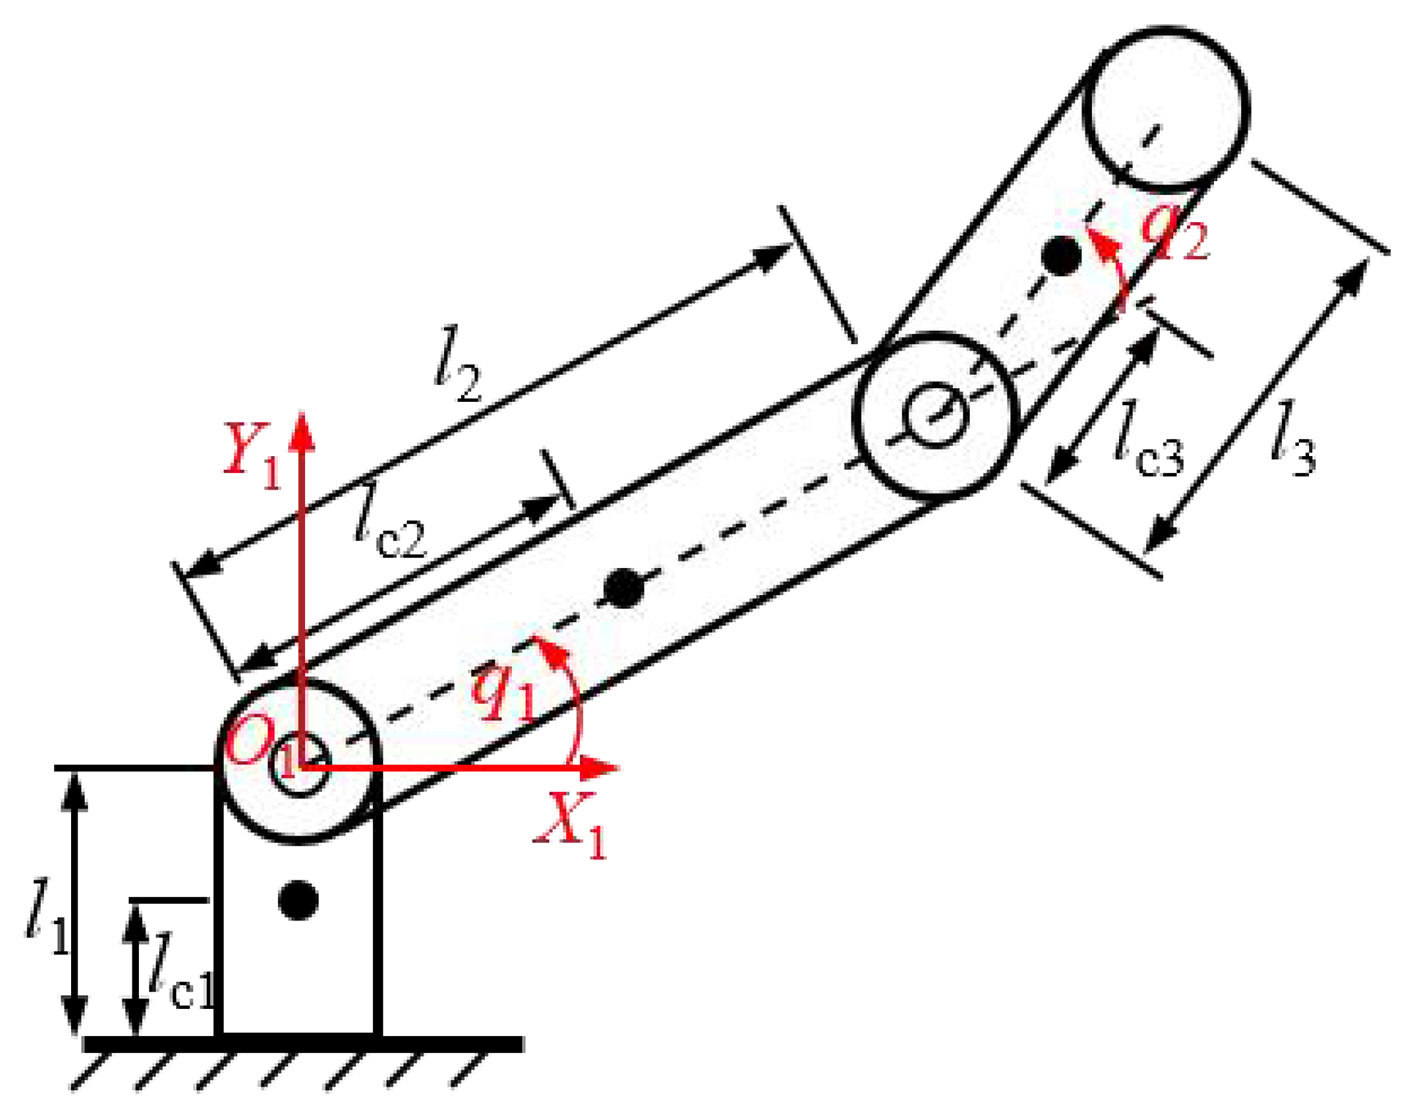
Figure 6. Coordinate systems and link length parameters of the dynamic model. l1, l2, and l3 are the lengths of the Support arm, lifting arm, and Rotating main arm, respectively.
Figure 6. Coordinate systems and link length parameters of the dynamic model. l1, l2, and l3 are the lengths of the Support arm, lifting arm, and Rotating main arm, respectively.


All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/