fig4
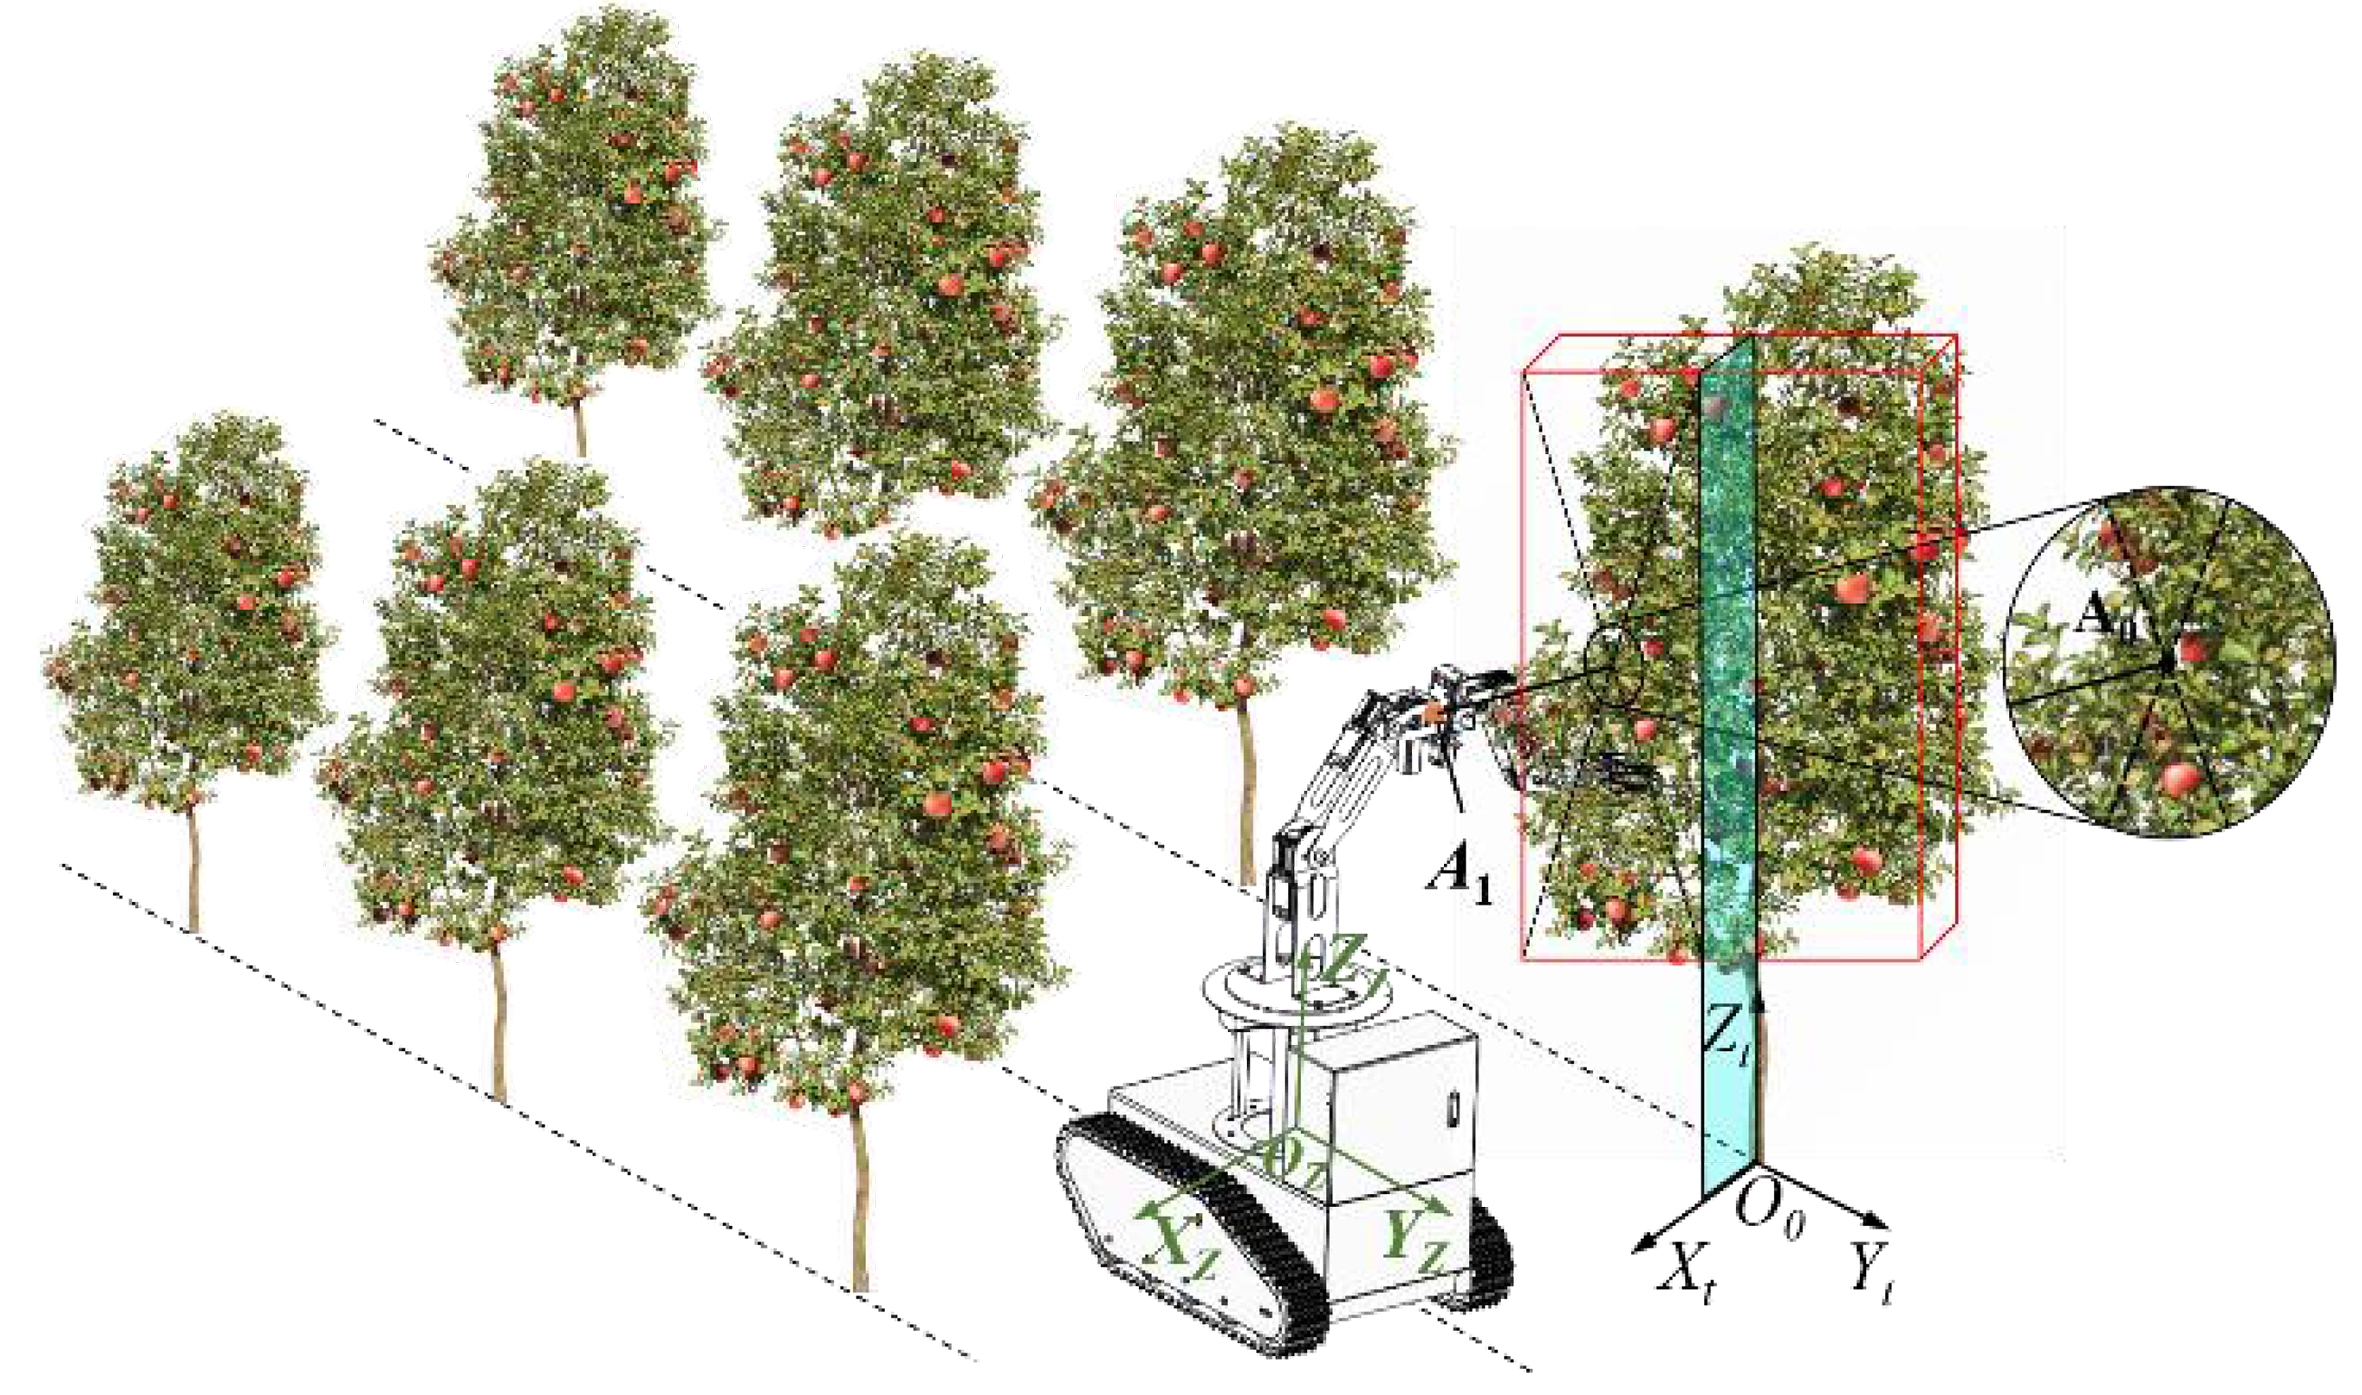
Figure 4. Schematic of the operating principle of the apple harvesting robot.
Figure 4. Schematic of the operating principle of the apple harvesting robot.


All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/