fig18
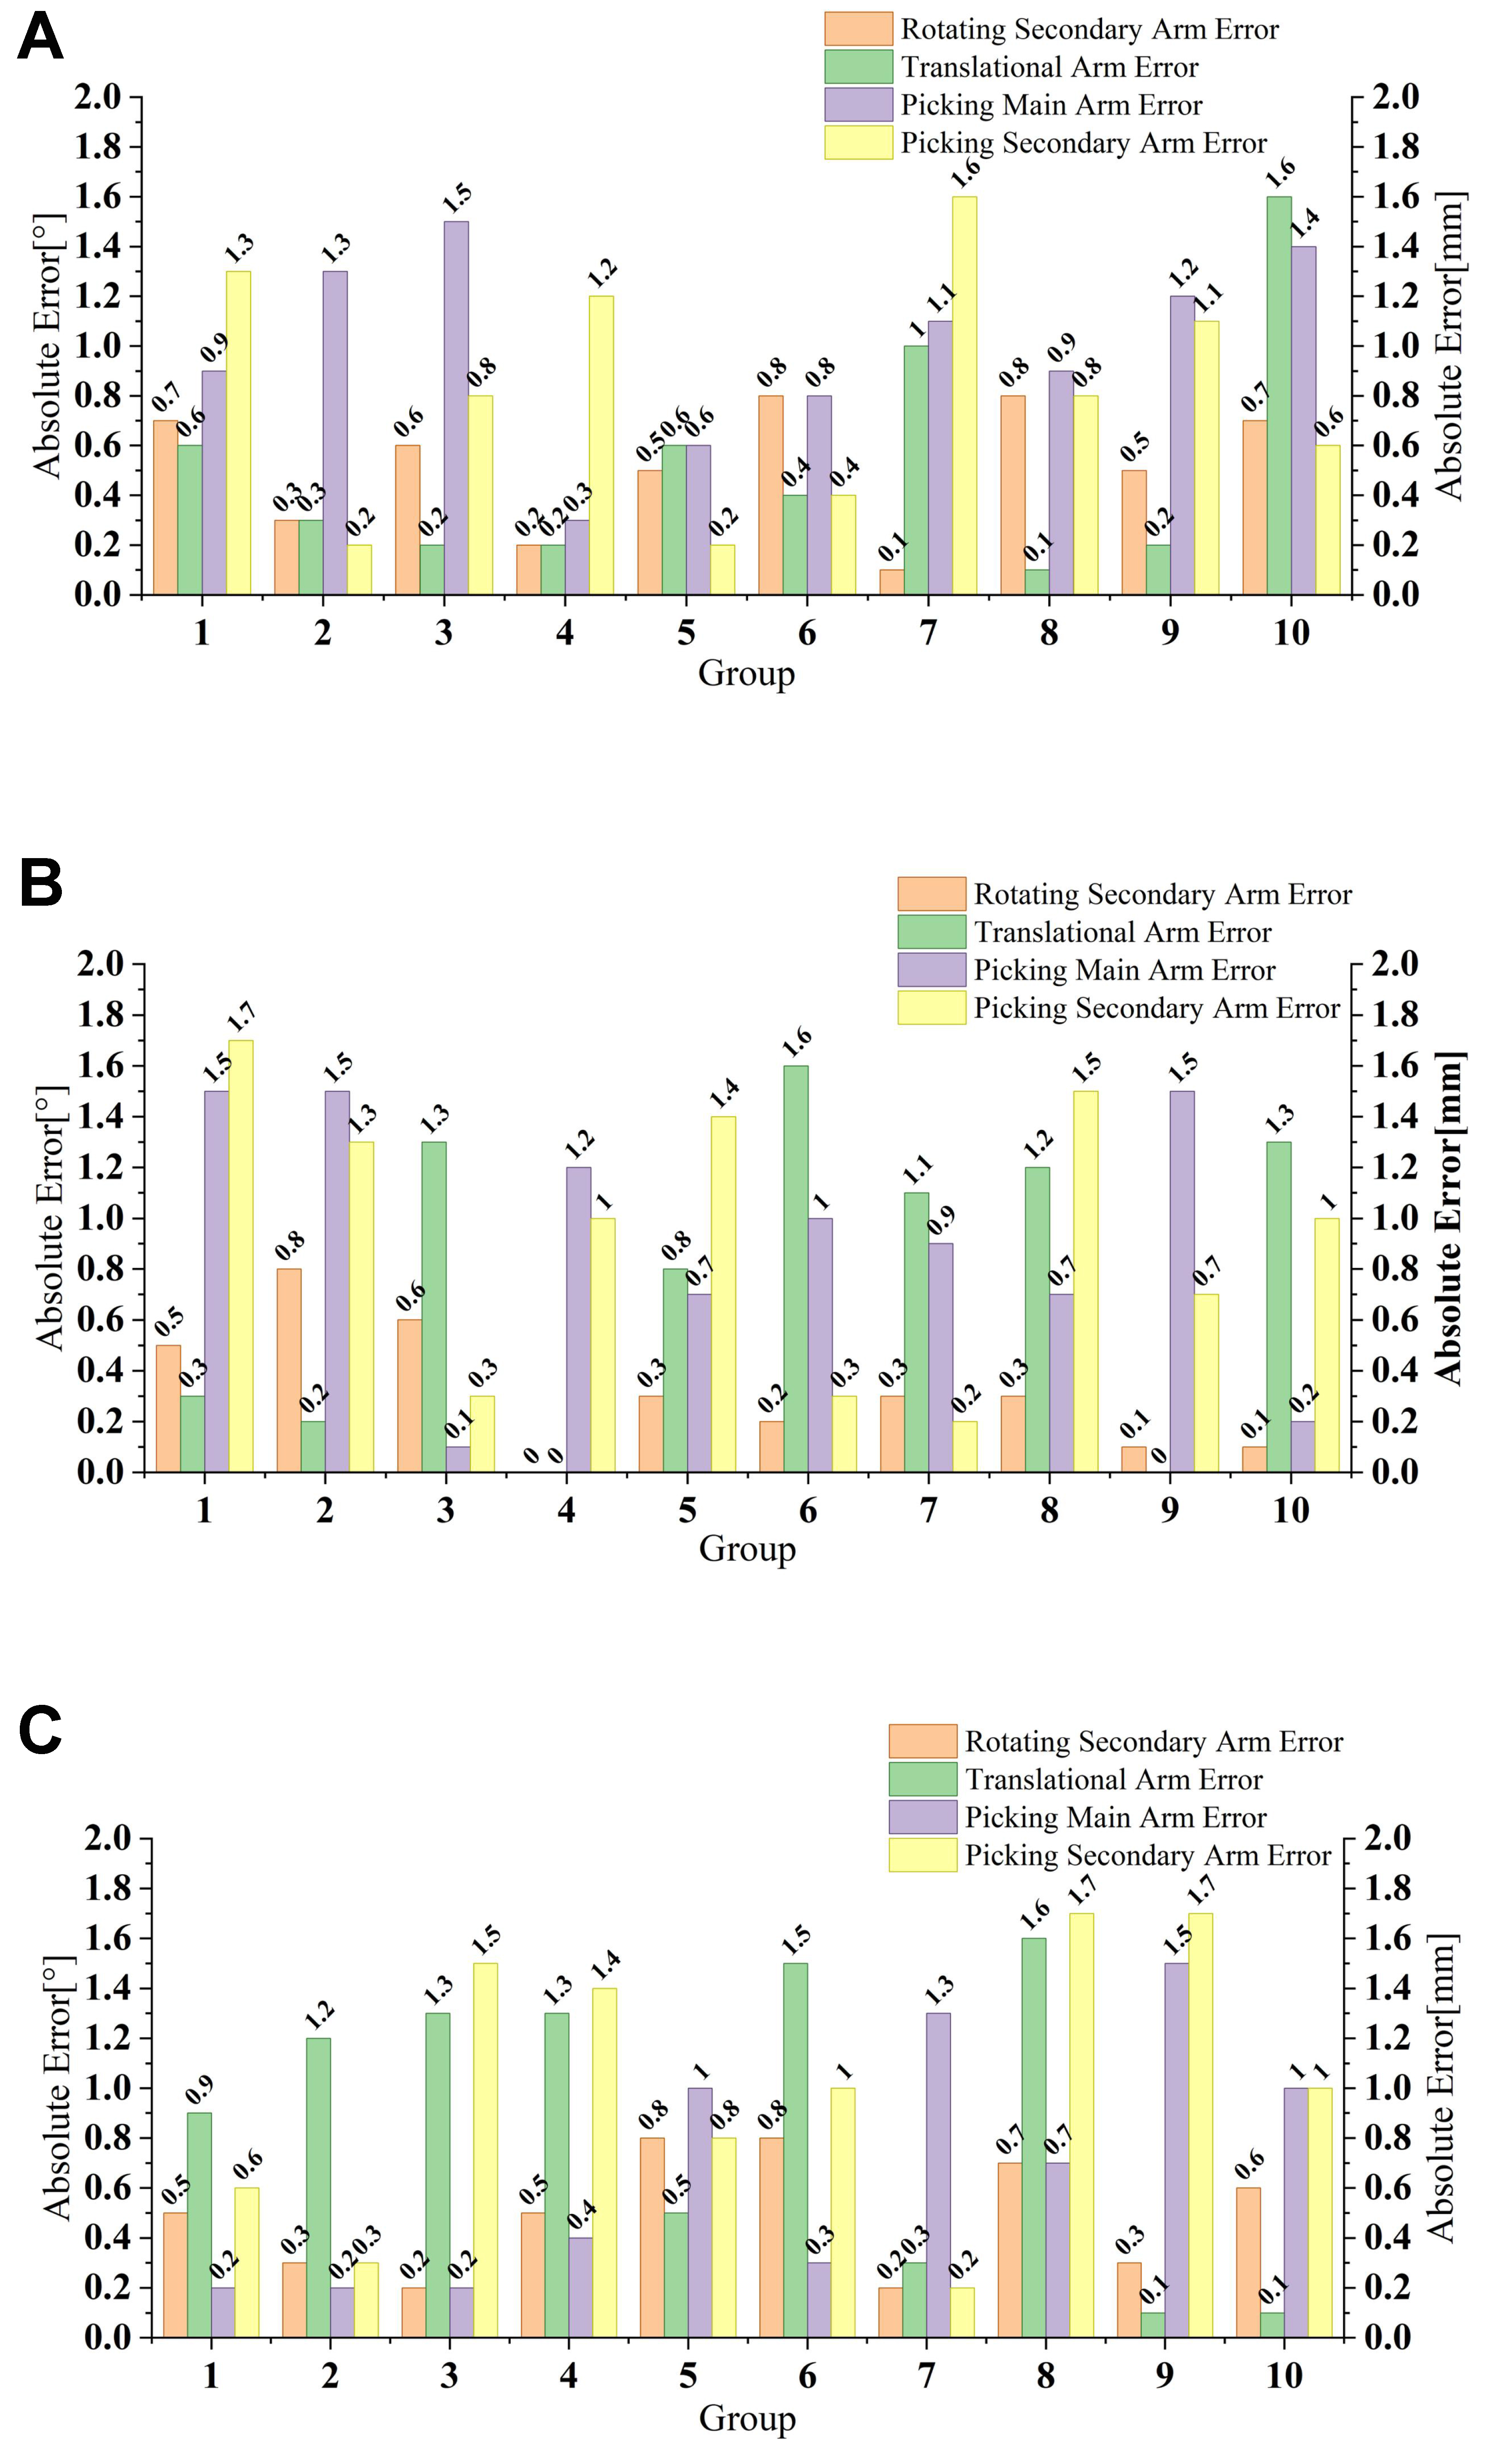
Figure 18. Absolute errors of joint rotation angles and displacement distances at reference points a2, a3, and a4. (A) Reference point a2; (B) Reference point a3; (C) Reference point a4.
Figure 18. Absolute errors of joint rotation angles and displacement distances at reference points a2, a3, and a4. (A) Reference point a2; (B) Reference point a3; (C) Reference point a4.


All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/