fig16
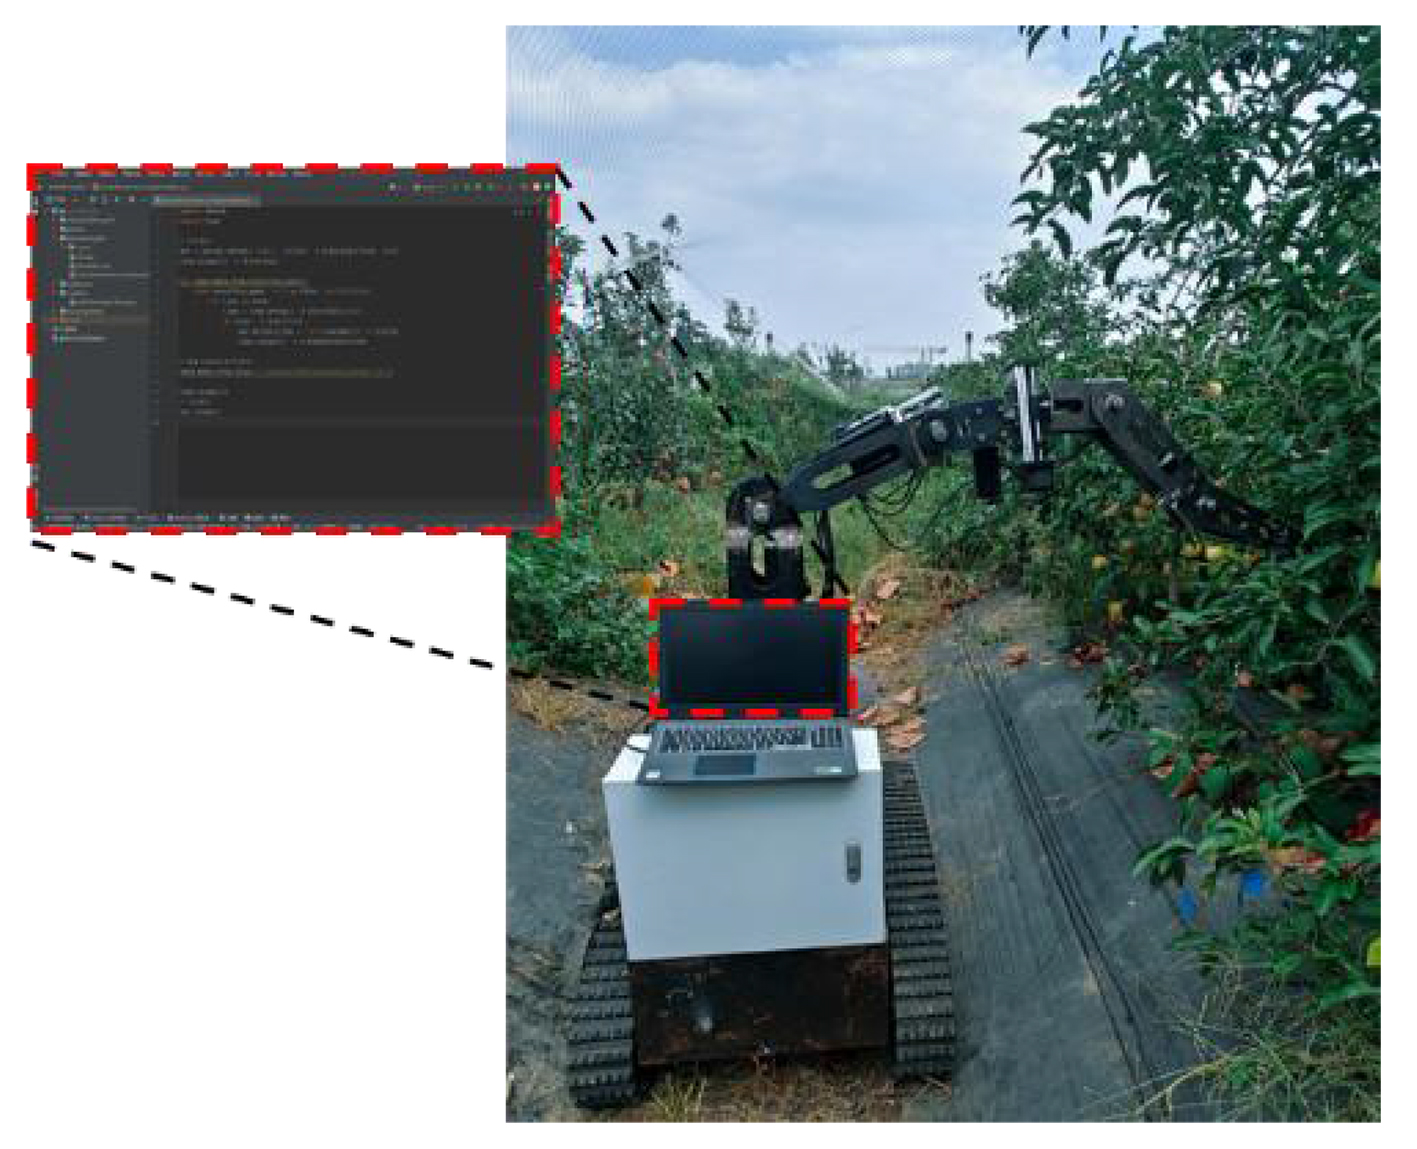
Figure 16. Picking performance test site. Photograph taken by the authors.
Figure 16. Picking performance test site. Photograph taken by the authors.


All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/