
fig15
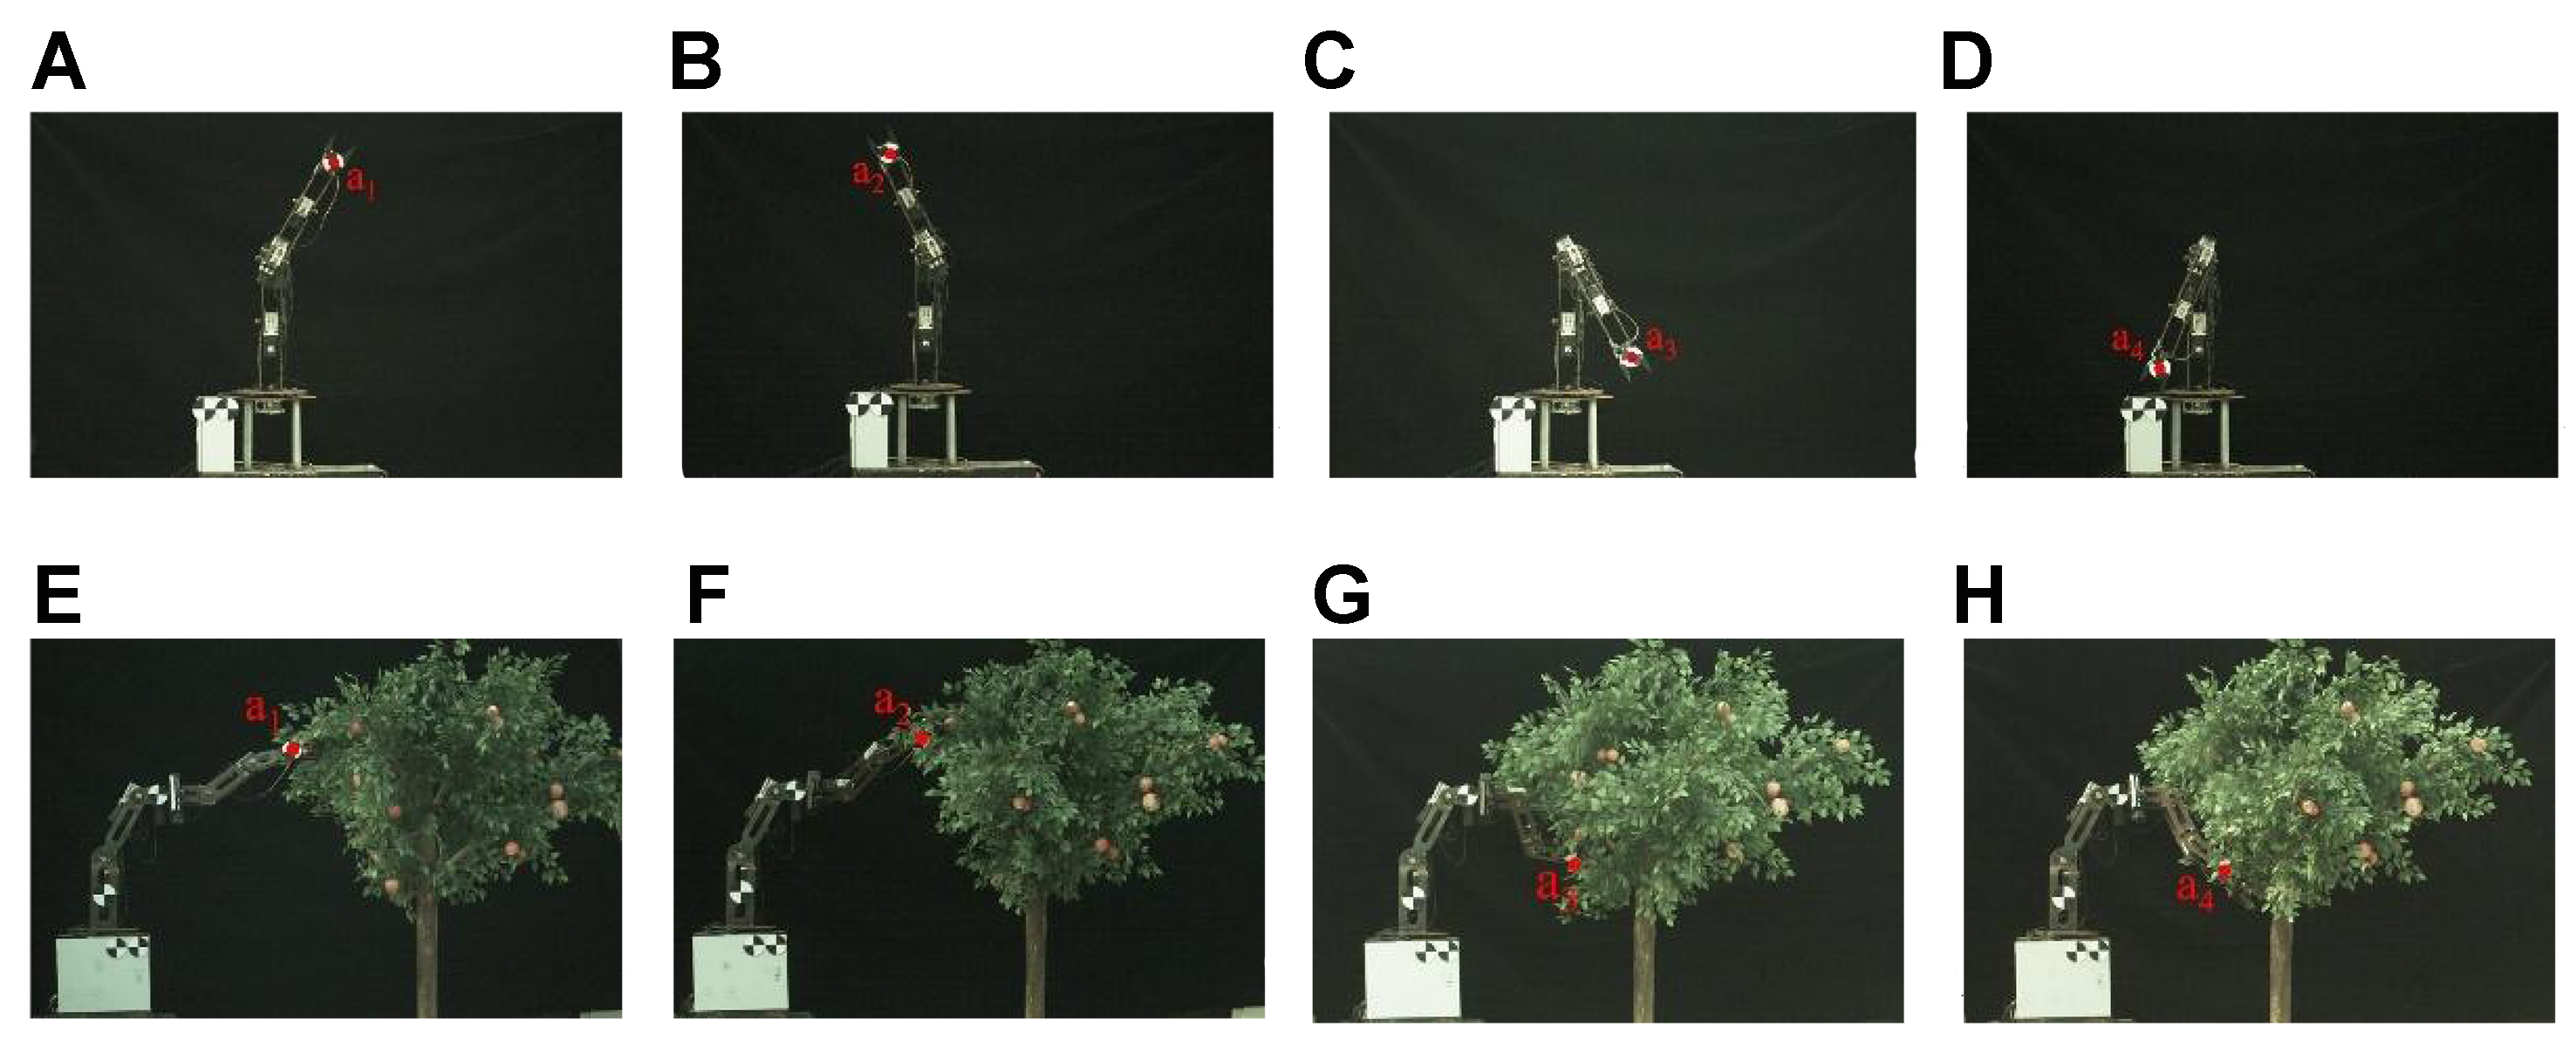
Figure 15. Final-frame images of reference points in the target picking domain under different axial directions. (A) Point a1 in the positive X0-axis direction; (B) Point a2 in the positive X0-axis direction; (C) Point a3 in the positive X0-axis direction; (D) Point a4 in the positive X0-axis direction; (E) Point a1 in the negative Y0-axis direction; (F) Point a2 in the negative Y0-axis direction; (G) Point a3 in the negative Y0-axis direction; (H) Point a4 in the negative Y0-axis direction. Photograph taken by the authors.