fig13
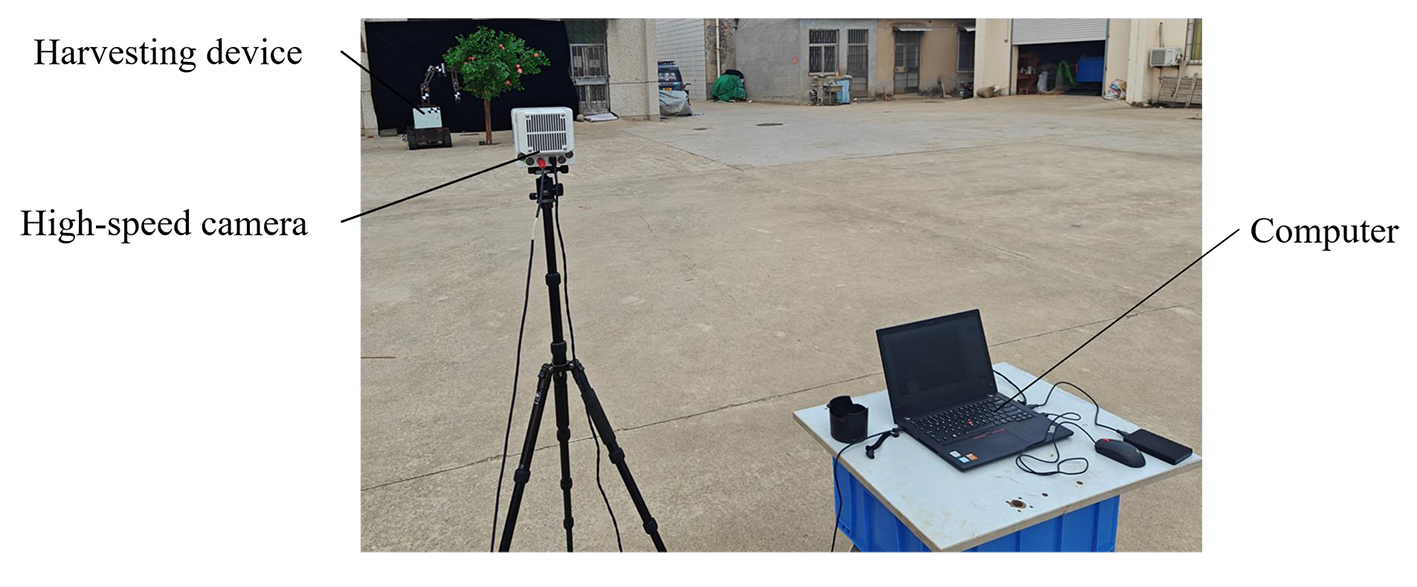
Figure 13. Experimental setup for boundary reference point tracking. Photograph taken by the authors.
Figure 13. Experimental setup for boundary reference point tracking. Photograph taken by the authors.


All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/