
Figure6
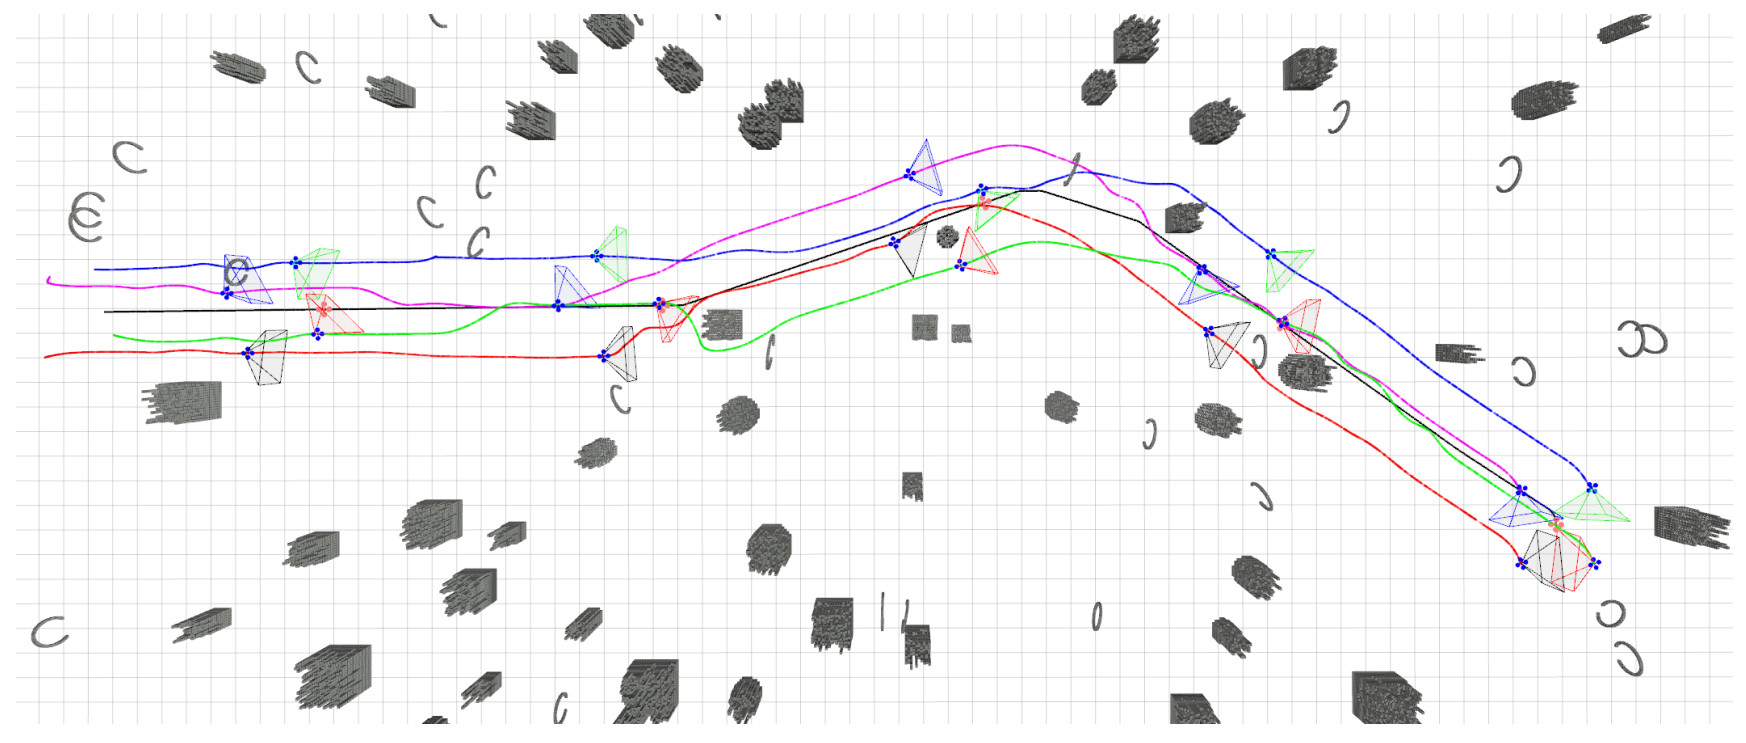
Figure 6. Simulation experiment. The four blue drones represent capture drones, while the red drone represents the target. Different colored curves indicate the movement trajectories of different drones, and different colored conical frames represent their fields of view. The corresponding video is provided as Supplementary Video 1.