
Figure5
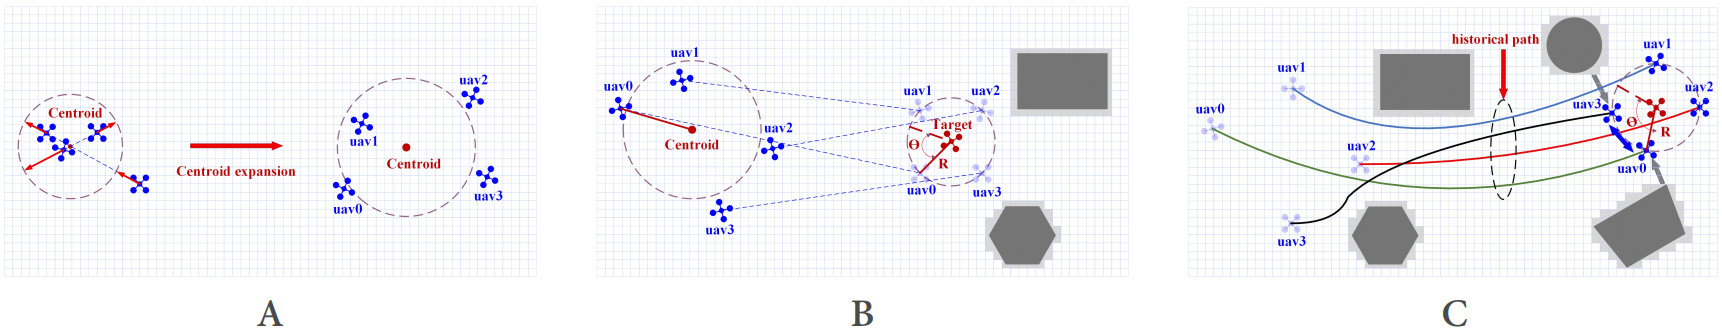
Figure 5. Target capture strategy generation: (A) illustrates the formation of a capture configuration by the drone swarm. The red dot represents the center of mass position of the swarm; (B) shows the capture points for each drone obtained by minimizing the objective function after the capture formation is established, when the surrounding area of the target is relatively open; (C) presents trajectory diagrams for dynamic target capture in dense environments. Curves of varying shades represent the historical trajectories of individual drones, with gray and blue arrows indicating obstacle avoidance factors and inter-drone collision avoidance factors, respectively. (C) also demonstrates how solutions to the objective function during capture alter the initial formation.