
Figure2
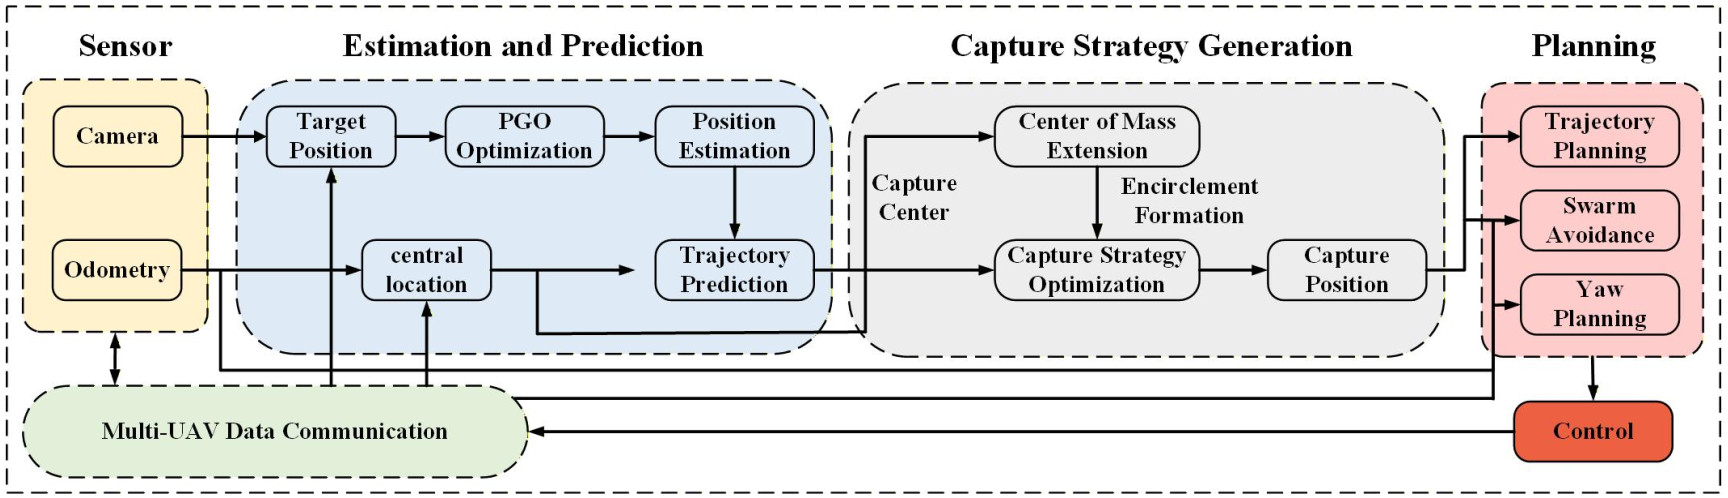
Figure 2. System Overview: This system is primarily divided into three aspects: Target Estimation and Prediction, Capture in Dense Environments, and Swarm Trajectory Planning. It employs a centralized computing approach to generate control commands for all drones, which are then transmitted via ROS communication. ROS: Robot operating system; PGO: pose graph optimization.