Leading Voices - Prof. Takeo Kanade
On September 29, 2026, the Editorial Office of Intelligence & Robotics (IR, ISSN: 2770-3541) had the honor of interviewing Prof. Takeo Kanade, Advisory Editor of IR, U.A. and Helen Whitaker University Professor at Carnegie Mellon University (CMU), and Member of the National Academy of Engineering (NAE), who is widely recognized as a pioneer in computer vision and robotics. The interview was conducted by Dr. Junfei Li, Junior Associate Chief Editor of IR and Assistant Professor at Lakehead University.
As the inaugural interview of the Leading Voices in Intelligence & Robotics series, launched to celebrate the fifth anniversary of IR, the conversation explored key questions surrounding robotic intelligence, embodied AI, and the transition from laboratory research to real-world applications.
Below are the details of the interview:
Questions:
Q1: The core of robotic intelligence
Robotic intelligence has traditionally been approached through different components, including perception, world modeling, planning, decision-making, and interaction with the environment. With recent advances in learning and embodied AI, these components are becoming increasingly interconnected. From your perspective, what is the most important source of intelligence in a robotic system? Is it better perception, better models of the world, better decision-making, interaction with the environment, or, more fundamentally, the integration of these capabilities? What do you see as the key connection between perception and action?
Q2: From perception to reliable physical action
Embodied AI aims to enable robots not only to perceive and understand the world, but also to act effectively within it. Yet translating perception and understanding into reliable physical action remains a major challenge. Drawing on your experience across computer vision, AI, and robotics, where do you see the most significant gap today between what a robot can perceive and what it can actually do? What capabilities do you think are still needed to close this gap?
Q3: From the laboratory to the real world
Many of your projects have tested ideas in demanding real-world environments. The NavLab program, for example, demonstrated vision-based autonomous driving decades before today’s rapid development of self-driving technology. When a robotic or autonomous system moves from a laboratory demonstration into the real world, what kinds of challenges tend to become much more important than researchers initially expect? What have these real-world experiences taught you about developing useful robotic systems?
Q4: Robots and the environments they operate in
Robotics has traditionally focused on developing robots that can adapt to environments designed for humans. But as robots become more capable and increasingly integrated into our daily lives, should we also rethink the environments in which they operate? How should we balance making robots more adaptable with designing environments, tools, and tasks that enable humans and robots to work together more effectively? More broadly, what role do you think robots should play in the environments of the future?
Q5: What assumptions should robotics reconsider?
You have witnessed several generations of ideas in AI and robotics emerge, become influential, and sometimes fade away. Looking at robotics today, particularly amid the rapid development of machine learning and embodied AI, what is one assumption that you think researchers should reconsider? Are there cases where the field may be placing too much emphasis on what is new, rather than on what is genuinely useful?
Q6: What should robotics ultimately achieve?
Throughout your career, you have helped bring computer vision, artificial intelligence, and robotics increasingly close together. As robotics continues to develop toward more intelligent and capable systems, what kinds of research questions would you most like to see the next generation of robotics researchers pursue? From your perspective, what should the field ultimately aim to achieve?
Q7: Advice for the next generation of robotics researchers
For young researchers who are beginning to pursue independent research in robotics, identifying meaningful research directions and building an independent research career can be challenging. Intelligence & Robotics has a growing community of young researchers and early-career scholars. What advice would you give to researchers at the beginning of their careers, particularly when it comes to choosing problems that are both scientifically meaningful and relevant to the real world?
About Prof. Takeo Kanade:
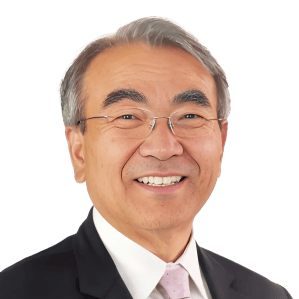
Prof. Takeo Kanade is the U.A. and Helen Whitaker University Professor of Computer Science and Robotics at Carnegie Mellon University (CMU), a Member of the U.S. National Academy of Engineering and the American Academy of Arts and Sciences, and an Advisory Editor of Intelligence & Robotics. He received his Ph.D. from Kyoto University, Japan, and previously served as Director of the Robotics Institute at CMU.
His research interests span computer vision, visual and multimedia technology, and robotics. He has made pioneering contributions to stereo vision, facial recognition, real-time dynamic sensing, and autonomous driving, with a long-standing focus on translating physical, geometric, and optical principles into computational models for intelligent systems. His work has received numerous prestigious honors, including the Kyoto Prize, the Bower Award and Prize for Achievement in Science from the Franklin Institute, and the ACM/AAAI Allen Newell Award. His pioneering work on Virtualized Reality™ and medical robotic systems has also led to impactful applications in sports broadcasting and clinical medicine.
About Asst. Prof. Junfei Li:
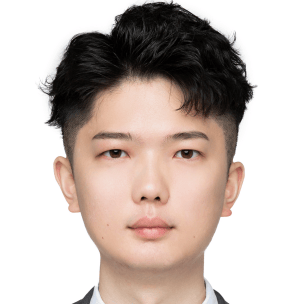
Dr. Junfei Li is an Assistant Professor in the Department of Mechanical & Mechatronics Engineering at Lakehead University, Canada, and Junior Associate Chief Editor of Intelligence & Robotics. He received his Ph.D. from the University of Guelph. His research interests include multi-robot systems, human–robot collaboration, and embodied intelligence, with a focus on combining bio-inspired mechanisms and artificial intelligence for real-time perception, decision-making, and coordination in complex dynamic environments. His research has been published in leading journals and conferences, including IEEE Transactions on Industrial Electronics, IEEE Transactions on Energy Conversion, and ICRA, with ongoing collaborations with industry to advance practical applications.
Editor: Jingya Wei
Production Editor: Xingyue Luo
Respectfully Submitted by the Editorial Office of Intelligence & Robotics