fig5
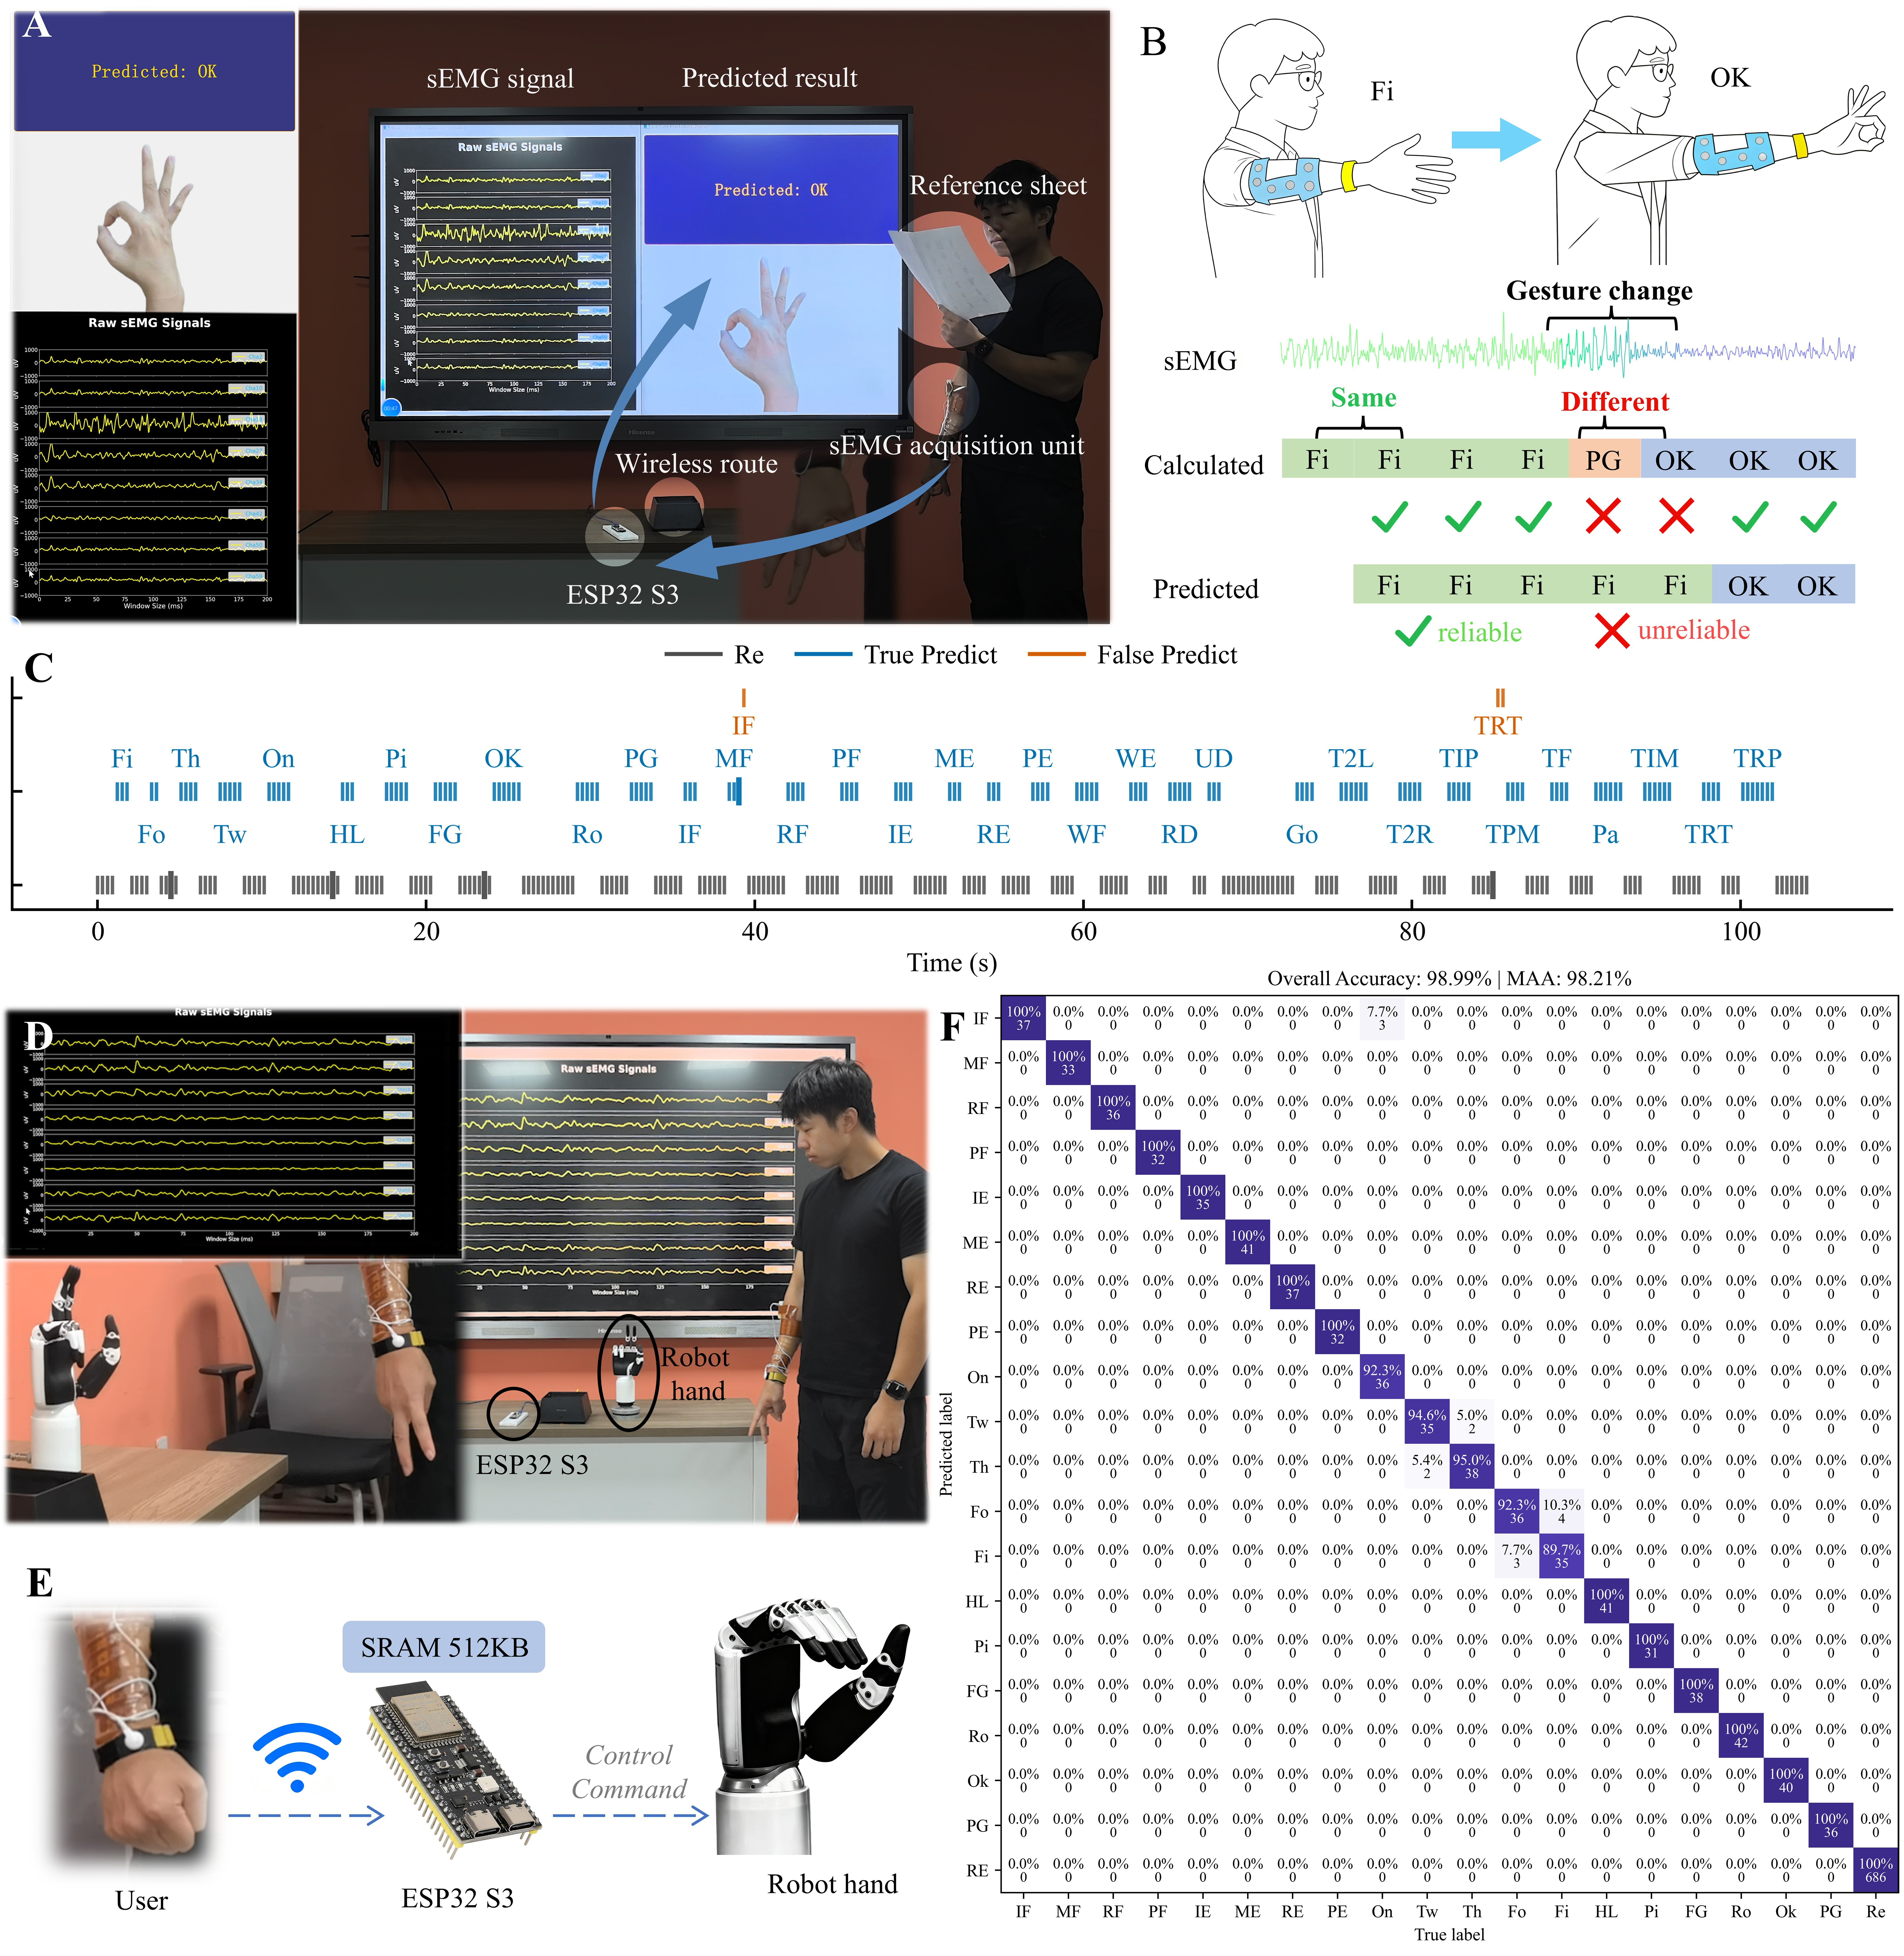
Figure 5. Data-centric paradigm enables effective edge deployment for on-site gesture recognition and robotic hand control. An online recognition experiment with 34 gestures is first conducted. (A) The experimental setup and module communication, where a post-processing strategy updates predictions only when consecutive windows are consistent (B), ensuring stable online recognition results (C). Thick non-red lines denote windows successfully corrected by post-processing; Subsequently, 20 gestures are selected according to the degrees of freedom of the robotic hand for real-time control (D), supported by the communication architecture among control modules (E); The overall robotic hand control accuracy reaches 98.99%, with an MAA of 98.21% (F). MAA: Macro-averaged accuracy; sEMG: surface electromyography.