
Soft Science Expert Interview Series – Prof. Seung-Kyun Kang
On 19 October 2026, the Editorial Office of Soft Science conducted an online interview with Prof. Seung-Kyun Kang, Professor in the Department of Materials Science and Engineering at Seoul National University (SNU), Seoul, Republic of Korea. Prof. Kang leads the Multi-Dimensional Materials (MDM) Lab, where his work spans materials science, mechanics, electronics, and bioengineering, focusing on transient and biodegradable materials, soft robotic systems, and minimally invasive bioelectronics.
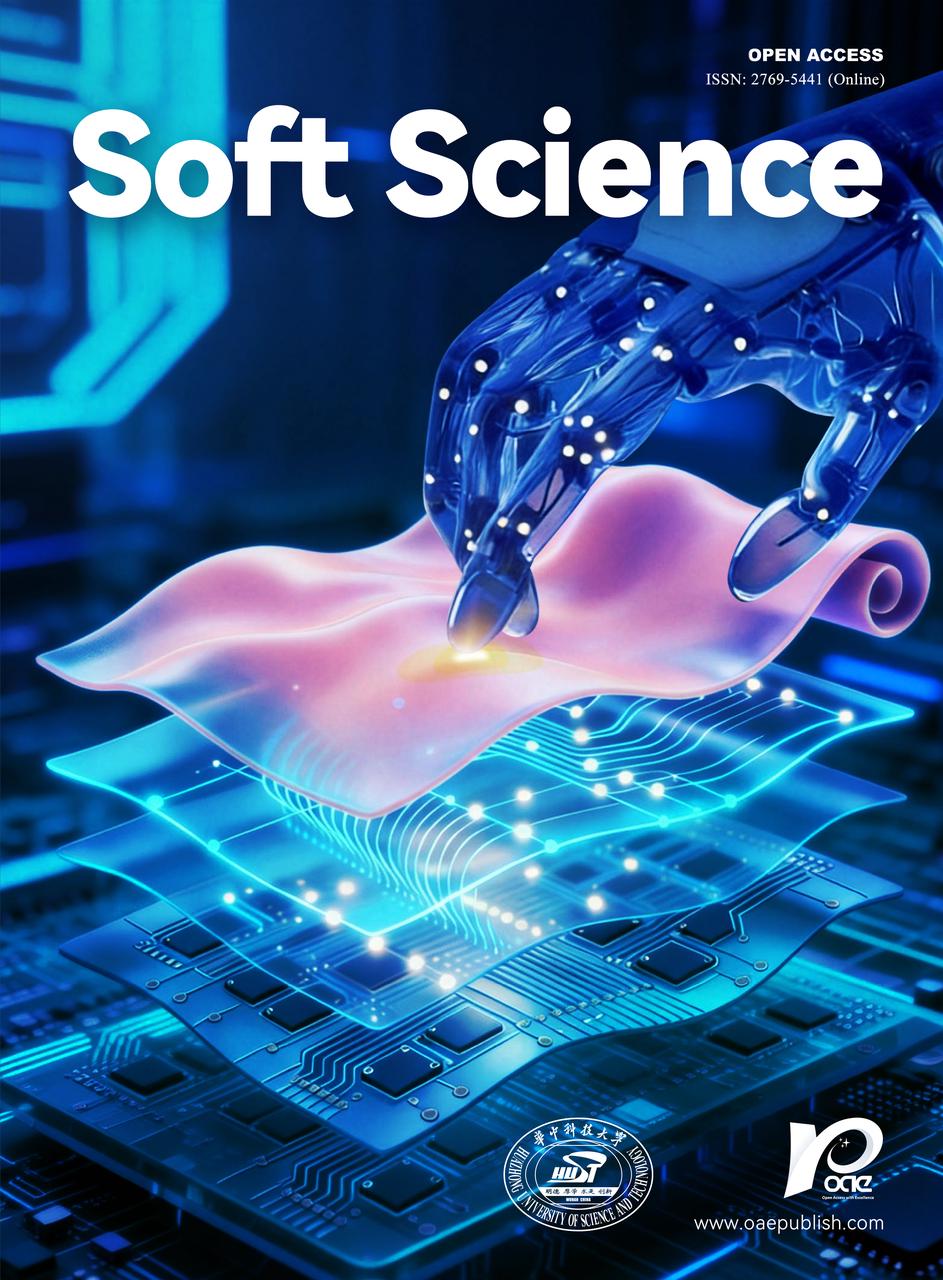
During the interview, Prof. Kang discussed his cover article "Laser-triggerable elastomeric composites for soft electronics and robotics" (Soft Science, Volume 6, Issue 3, 2026, Article 47; DOI: 10.20517/ss.2026.07), co-authored with K.-S. Kim and M.-H. Oh. Conventional transient devices break down passively under moisture or biofluid, and the onset and rate of degradation are difficult to control precisely. The present study develops a silicone elastomer composite that can be degraded on demand from a distance: Fe₃O₄ nanoparticles act as photothermal transducers that convert femtosecond laser irradiation (800 nm, stand-off distance exceeding 5 m) into localized heat, activating DPI-HFP (diphenyliodonium hexafluorophosphate) to release fluoride ions that cleave Si–O bonds in the elastomer. Compared with direct laser ablation of pristine silicone or the conventional UV-plus-heat route, the composite decomposes at a much lower energy input while remaining highly elastic and mechanically stable before triggering. Prof. Kang stressed that the central design task is to balance three competing requirements: flexibility and mechanical robustness before activation, a selective response to the remote trigger, and a rapid, self-accelerating decomposition once initiated.
At the device level, the team demonstrated spatially selective erasure of stretchable electronic components, including strain and temperature sensors and transistor arrays, together with contact-free reprogramming of transformable soft actuators; for instance, a legless soft crawler could be remotely triggered to extend its legs and climb over steps. Prof. Kang noted that such permanent, post-deployment reconfiguration opens possibilities for robots operating in inaccessible environments, from space-exploration missions to hazardous-field surveillance. In the biomedical domain, precise lifetime control is especially important for implantable devices, where encapsulation layers protect the device yet make the timing of degradation harder to tune. Looking ahead, he hopes this work encourages the community to design soft devices from a full life-cycle perspective—working reliably, adapting to their surroundings, and then degrading or changing function by plan rather than by accident—while addressing open challenges such as ambient stability, trigger selectivity, and self-sustaining reactions that require no additional external power after initiation.
Watch the full interview with Prof. Seung-Kyun Kang:
Interview Questions:
Q1. Congratulations on your paper being selected as the cover article of Soft Science! Looking back to the beginning of this project, what first sparked your interest in exploring remotely triggerable transient materials?
Q2. For readers who may be seeing this work for the first time, could you walk us through the central idea of the study and the key advance it offers?
Q3. Your system combines Fe₃O₄ nanoparticles, DPI-HFP, and a silicone elastomer to achieve remotely triggered decomposition. What were the key considerations behind this material design, and how did these components work together to achieve the desired response?
Q4. You demonstrated both selective erasure and remote reprogramming of soft actuators. What do these demonstrations reveal about the broader possibilities of your material beyond the material-level results?
Q5. Looking ahead, what are the most exciting research directions your team hopes to pursue in transient soft electronics and soft robotics over the next few years?
Q6. Finally, beyond the specific results presented in this paper, what do you hope this work will inspire researchers in the broader soft electronics and soft robotics community to think about or explore?
About the Interviewee:
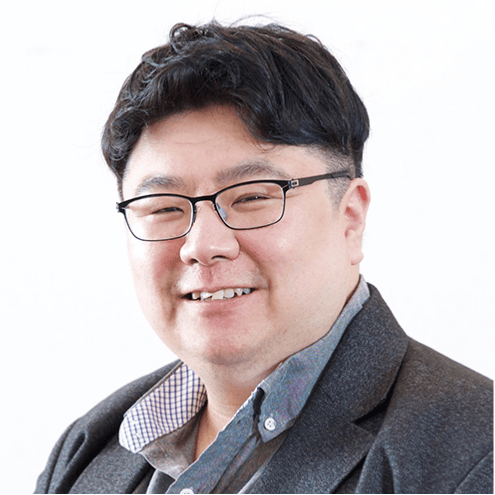
Prof. Seung-Kyun Kang (강승균)
Department of Materials Science and Engineering, Seoul National University, Seoul 08826, Republic of Korea
Prof. Kang received his B.S. (2006) and Ph.D. (2012) in Materials Science and Engineering from Seoul National University. He was a Postdoctoral Researcher at the University of Illinois at Urbana-Champaign (2012–2016), a Postdoctoral Researcher at the Center for Bio-integrated Electronics, Northwestern University, Evanston, IL, USA (2016–2017), and a Visiting Researcher in Materials Science and Engineering at UIUC (2016–2017). He served as an Assistant Professor in Bio and Brain Engineering at KAIST, Daejeon, Republic of Korea (2017–2019), before joining SNU as an Assistant Professor in Materials Science and Engineering (2019–2021); he was promoted to Associate Professor (2021–2026) and, in 2026, to Professor. His research has been reported in journals including Nature Sustainability, Nature Electronics, Science Advances, Advanced Functional Materials, and Soft Science.
Research Interests
- Transient and biodegradable materials for soft electronics
- Remotely triggerable elastomers, soft actuators, and shape-reconfigurable soft robots
- Biodegradable, minimally invasive implantable bioelectronics and neural/brain interfaces
- Zero-waste, compostable green electronics and sustainable soft systems
- Device encapsulation, ambient stability, and reliability of flexible and wearable electronics
- Multidisciplinary integration of materials, mechanics, electronics, and bioengineering
Editor: Lydia Li
Production Editor: Xingyue Luo
Respectfully Submitted by the Editorial Office of Soft Science