fig9
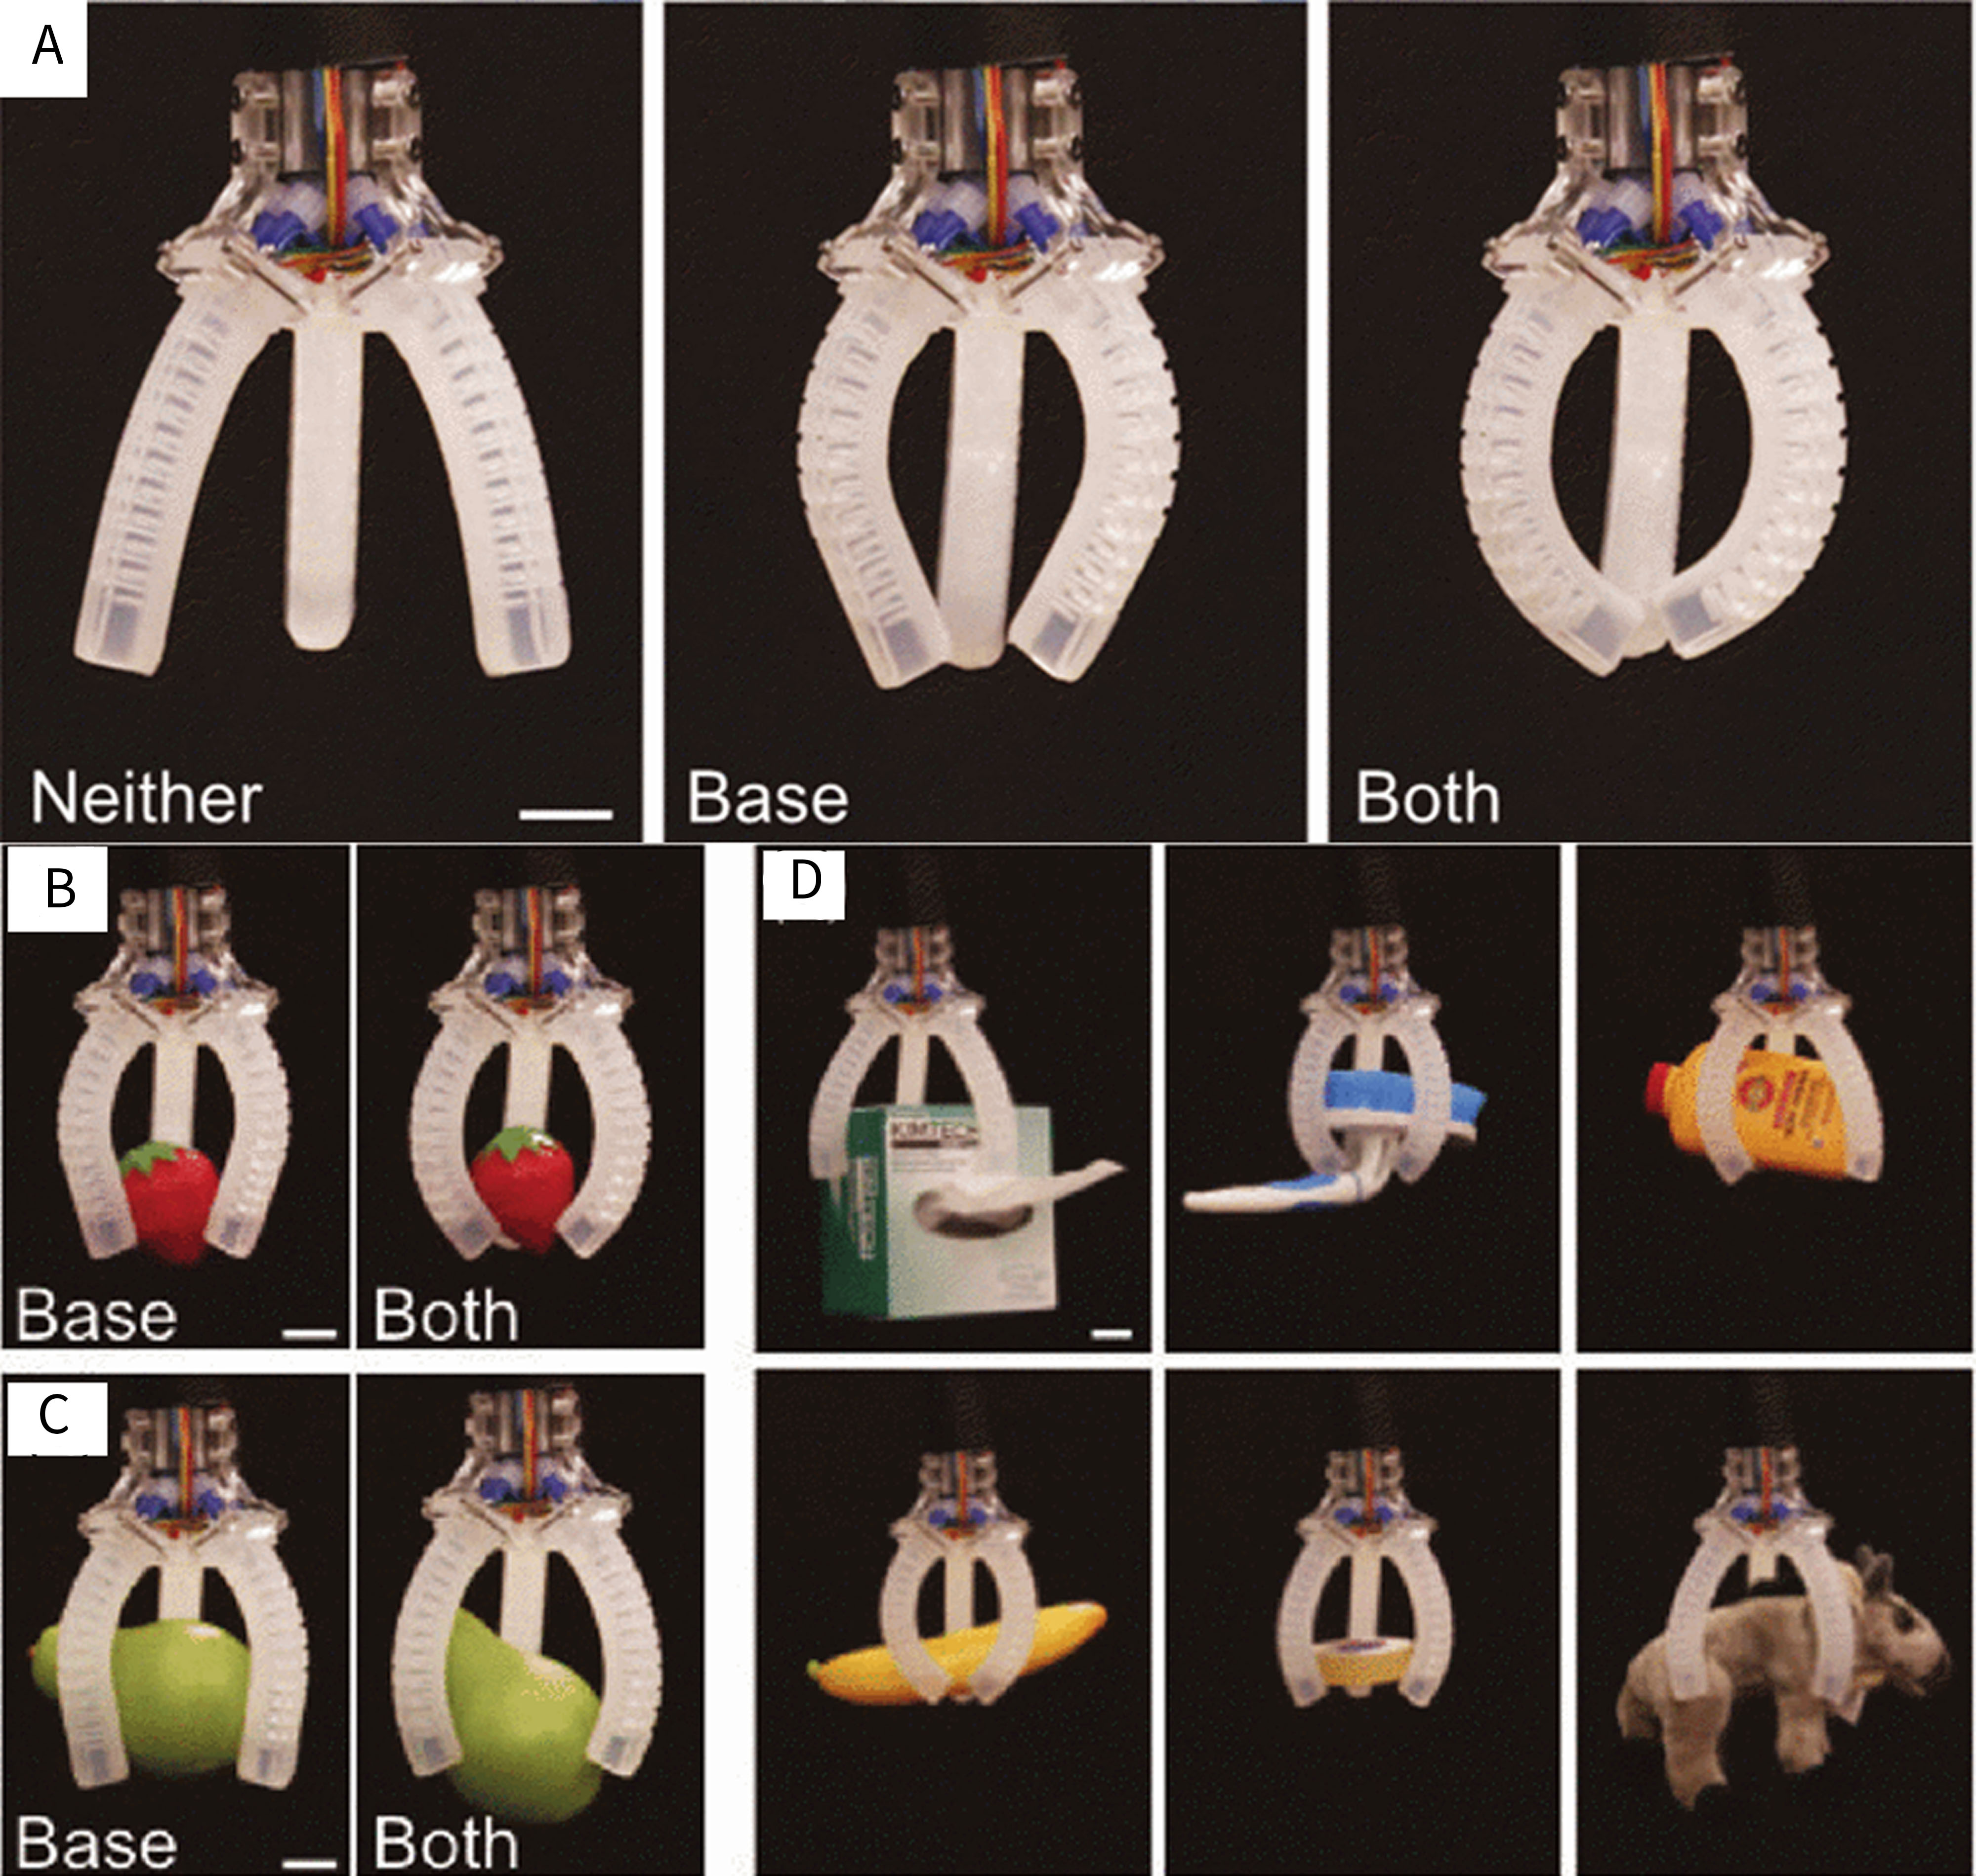
Figure 9. Flexible gripping robot utilizing ionogel sensors for object manipulation. (A) Examples of manipulator poses. Photographs of the soft gripper during no (left), base-only (center), and full-finger actuation at inflation pressure of 140 kPa. Scale bar is 15 mm; (B-D) Examples of object grasping; (B and C) Examples of grasping poses are shown for holding a toy strawberry (B) and pear (C) during base-only (left) and full-finger actuation (right); (D) Examples of objects that can be grasped by the soft gripper with appropriate pre-grasp orientation. Inflation pressure is 140 kPa in each photograph. Scale bars are 15 mm. (A-D) Reproduced with permission from ref.[31], Copyright 2019, IEEE.